How to Manufacture Motor De Drone?
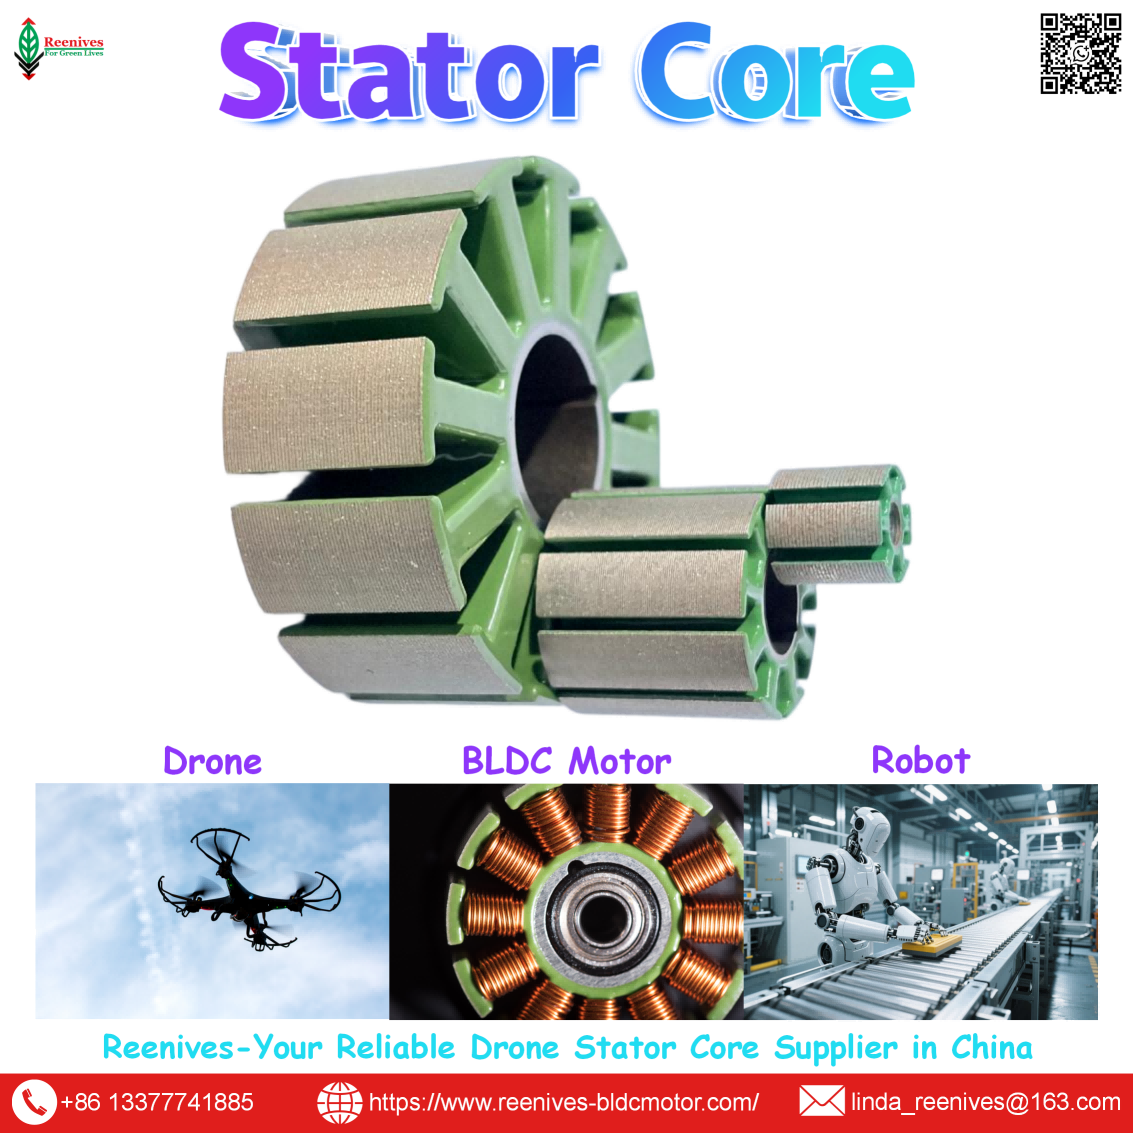
How to Manufacture Motor De Drone: The Five-Stage Workflow and the Stator Core Parameters That Decide Yield
Most “how to manufacture a drone motor” guides start with the winding machine and the assembly line. They start one step too late. A brushless drone motor — motor de drone in the Spanish-speaking sourcing market — is manufactured through five controlled stages: stator core fabrication, stator winding, rotor assembly, stator-rotor mating, and end-of-line testing. The first stage sets the boundary that the other four work inside. A stator core with a burr at the top of its tolerance band will pierce its own interlamination coating during stacking, and the resulting turn-to-turn short will be detected only at the end-of-line surge test — after every station has added cost to a motor that will be scrapped. The winding machine did its job. The incoming core did not.
Key takeaways — in brief:
A 0.20 mm lamination grade at ≤9.5 W/kg cuts iron loss roughly 31% versus 0.35 mm at drone electrical frequency, which becomes ~15°C lower winding temperature and ~8–12% more continuous torque before thermal derating.
Winding holds ±0.05 N tension and ±0.03 mm placement; mating holds a 0.3 ± 0.05 mm air gap at 500–1,000 N; balancing runs to G2.5; 100% Hi-Pot plus surge testing closes the line.
The line’s yield is the product of machine capability and incoming part conformance — and the stator core bounds the most stations.
This guide is written for the procurement or process engineer who has to build, qualify, or cost a drone motor production line, not for a hobbyist. It walks through each of the five stages with the published tolerance that stage must hold, the failure mode it prevents, the stator core specification that the stage depends on, and the audit question that separates a production line from a prototype bench.
In this guide — jump to the section your project needs:
- What Does It Mean to Manufacture Motor De Drone? The Five-Stage Definition
- Production Line Classification: Fully Automatic, Semi-Automatic, and Flexible Multi-Model Lines
- Published Parameters by Stage: Stator Core, Winding, Rotor, Mating, and End-of-Line Test
- Application Profiles: Which Stage Binds Which Drone Mission
- A 5-Step Manufacturing Readiness Audit for Procurement Engineers
- FAQ: Stages, Stator Core Priority, Lamination, Tension, Air Gap, EOL Tests, and Yield Cost
- Summary: Build the Core First, Then the Motor
What Does It Mean to Manufacture Motor De Drone? The Five-Stage Definition
Manufacturing a brushless drone motor is the process of converting electrical steel, enameled copper, permanent magnets, bearings, shafts, and housings into a balanced, tested machine that converts battery current into propeller thrust. The production-grade workflow runs through five controlled stages, and each stage has a defined control point that a buyer can audit.
| Stage | Core Operation | Primary Control Point | Published Tolerance / Data |
|---|---|---|---|
| 1 · Stator core | Stamping, stacking, interlocking or bonding, insulation coating | Burr height, core loss, stacking factor, concentricity | Burr <0.03 mm; core loss ≤9.5 W/kg @ 1.0 T / 400 Hz per IEC 60404-2; stacking factor ≥97%; concentricity ≤0.02 mm |
| 2 · Winding | Enameled copper inserted into slots, terminated, impregnated | Tension, placement accuracy, phase resistance balance | Tension ±0.05 N; placement ±0.03 mm; tooling ±0.02 mm; flyer 2,000–5,000 rpm |
| 3 · Rotor assembly | Shaft machining, magnet bonding, bearing seats, dynamic balancing | Shaft tolerance, magnet polarity, balance grade | Shaft ~±0.005 mm; balance G2.5 at >10,000 rpm; residual unbalance ~3 mg |
| 4 · Mating | Servo-driven stator-rotor mating with sensor verification | Air gap, alignment, press force | Air gap 0.3 ± 0.05 mm; press 500–1,000 N; alignment ≤0.05 mm; force ±5% |
| 5 · End-of-line test | Electrical, mechanical, and no-load performance verification | Insulation integrity, KV, current, balance | 100% Hi-Pot, surge, 3-phase resistance, no-load current, speed, noise, temperature rise, 3-phase balance |
Sources: Reenives 0.20 mm laminated stator core specification (core loss, stacking factor, concentricity, burr); published BLDC stator winding process data (tension, placement, tooling, flyer speed); published drone assembly guidance (shaft tolerance, mating alignment and force); published drone motor line air-gap and press data (0.3 ± 0.05 mm, 500–1,000 N); published drone motor testing platform data (balancing G2.5, ~3 mg, 100% EOL coverage).
Procurement translation: a supplier who quotes a winding machine, an assembly jig, and a test bench has described three stages out of five. The two stages that decide whether the line produces conforming motors are stage 1 (the stator core specification) and stage 4 (the air-gap mating control). Ask which supplier owns the core, what the core-loss and burr records show, and how the mating force and alignment are verified. Those answers separate a production line from a bench.
Production Line Classification: Fully Automatic, Semi-Automatic, and Flexible Multi-Model Lines
| Line Configuration | Automation Level | Published Capability | Changeover | Best Fit |
|---|---|---|---|---|
| Fully automatic line | Multi-station rotary table, zero manual intervention at winding and assembly | 98% yield at 400 pcs/h; ±0.01 mm assembly positioning; AI vision defect recognition >99.5% | ~25 minutes for multi-specification changeover | High-volume drone motor production with a stable model mix |
| Semi-automatic line | Automatic winding and balancing; manual loading, soldering, and packing | Flyer winding 2,000–5,000 rpm; balancing to G2.5 | 15–25 minutes with quick-change fixtures | Mid-volume production and prototyping before full automation |
| Flexible multi-model line | Modular stations with quick-change tooling and MES recipe switching | Shared stamping, annealing, and coating units; inspection recipes switched per model | ≤15 minutes die change; 25 minutes equipment change | Suppliers serving several drone SKUs at varying volumes |
Sources: Published fully automatic drone motor line data (98% yield, 400 pcs/h, ±0.01 mm positioning, AI vision >99.5%); published semi-automatic winding and balancing parameters (flyer 2,000–5,000 rpm, G2.5); published changeover data (≤15 min die change, 25 min equipment change).
The configuration decision is a volume and model-mix decision, not a quality decision. A semi-automatic line with a closed-loop tension controller can produce a stator as electrically clean as a fully automatic line; it simply does so at lower throughput and with more operator dependency. The fully automatic line’s value appears when the annual volume justifies the tooling and integration cost, and when the model mix is stable enough that changeover does not erode the throughput advantage. In every configuration, the stator core constraint is identical: the line’s yield is bounded by the incoming core conformance, regardless of how automatic the motion sequence is.
Published Parameters by Stage: Stator Core, Winding, Rotor, Mating, and End-of-Line Test
Stage 1 — Stator core fabrication
The stator core is produced by high-speed progressive stamping of non-oriented electrical steel, followed by stacking, interlocking or bonding, and insulation coating. The published specification that the stage must deliver is the value-plus-standard-plus-location set: core loss ≤9.5 W/kg at 1.0 T / 400 Hz per IEC 60404-2 on the finished stack, B50 flux density 1.65–1.72 T, stacking factor ≥97% by the weight/dimension method, concentricity ≤0.02 mm by vision, critical tolerance ±0.05 mm, burr height <0.03 mm by optical comparator, and C5 epoxy coating at >1400 V per ASTM D149.
Each of those values maps to a later stage. Burr height determines whether the coating survives stacking and winding. Stacking factor determines the flux density the winding can link. Concentricity determines half the air gap the mating stage must hold. Core loss determines the thermal budget the motor must not exceed. A core that passes a visual check but misses one of these values does not fail at stage 1 — it fails at stage 5, after every other stage has added value.
Stage 2 — Stator winding
Published winding process data for drone stators specifies wire tension fluctuation within ±0.05 N, wire placement accuracy better than ±0.03 mm, and tooling alignment to ±0.02 mm. The purpose is stated directly in the source: these controls prevent wire crossover, skipped turns, and enamel insulation damage. For outrunner drone motors with outward-facing slots, external flyer winding runs at 2,000–5,000 rpm. Concentrated winding is the default because it shortens end turns and reduces the copper mass that adds weight without contributing torque. After winding, published assembly practice includes vacuum impregnation to reinforce the insulation barrier before the stator is integrated.
Stage 3 — Rotor assembly
The rotor stage sets the other half of the air gap. Published assembly guidance specifies shaft machining to a key dimension tolerance of approximately ±0.005 mm, magnet installation with controlled adhesive dispensing and curing, and dynamic balancing on a machine supporting speeds above 10,000 rpm and achieving G2.5 grade with residual unbalance around 3 mg. The rotor stage creates the balance state; the mating stage cannot correct an unbalanced rotor, and the end-of-line test can only reject it.
Stage 4 — Stator-rotor mating
The mating station sets the air gap physically, and it is where the accumulated tolerances either cancel or compound. Published drone assembly guidance specifies servo-driven mating with high-precision encoder feedback, alignment error ≤0.05 mm, and mating force within ±5% of design — for example 1,000 N ± 50 N — to avoid gap distortion from over- or under-press. Published drone motor line data targets an air gap of 0.3 ± 0.05 mm with a 500–1,000 N press at ≤2 seconds per part. Post-mating sensors verify that no magnets or coils are missing before electrical testing.
The stage-4 amplification trap: the mating station cannot correct a core that is already out of tolerance. If the stator bore concentricity is at 0.05 mm instead of 0.02 mm, the mating press will close the gap at the commanded force, but the gap will be non-uniform. The end-of-line no-load test may show a slightly elevated vibration reading, and the motor may still ship. In the field, that non-uniform gap becomes bearing load, which becomes eccentricity, which becomes vibration — the feedback loop that published analysis identifies as the dominant cause of axial and radial motor bearing failures. The mating station is where the accumulated core tolerance becomes a motor that either holds its air gap or does not.
Stage 5 — End-of-line testing
Published drone motor testing platforms perform 100% no-load testing before shipment, monitoring KV value and no-load current, and screen every motor against qualified performance before delivery. The electrical test set includes Hi-Pot testing, resistance and inductance testing, and surge waveform testing. The no-load test covers no-load current, speed, noise, temperature rise, and three-phase balance, with out-of-tolerance units automatically rejected. The surge test is the critical differentiator: a turn-to-turn short can leave total phase resistance within tolerance while creating a hot spot under load, so a resistance-only check passes the defect.
Application Profiles: Which Stage Binds Which Drone Mission
| Mission Class | Binding Manufacturing Stage | Why | Specification to Write |
|---|---|---|---|
| FPV racing / high-RPM | Stage 2 (winding) and Stage 3 (rotor balance) | Fine wire at 1,000+ Hz electrical exposes enamel damage and unbalance immediately | Tension ±0.05 N; placement ±0.03 mm; balance G2.5 at >10,000 rpm |
| Cinematic / inspection FPV | Stage 4 (mating alignment) | Vibration reaches the camera before it reaches the pilot; air-gap uniformity governs vibration | Alignment ≤0.05 mm; air gap 0.3 ± 0.05 mm; concentricity ≤0.02 mm |
| Agricultural spraying UAV | Stage 1 (coating) and Stage 5 (thermal test) | Long, wet, thermal duty cycle stresses the insulation barrier | C5 epoxy >1400 V per ASTM D149; temperature rise verified at 100% |
| Heavy-lift / logistics UAV | Stage 1 (stacking factor) and Stage 4 (press force) | Continuous torque depends on flux density from a tight stack and a uniform gap from controlled force | Stacking factor ≥97%; press 500–1,000 N; finished-stack core loss report |
| Multi-model production | Changeover discipline across all five stages | A model switch re-baselines every stage; first-off inspection is the only control that catches a mis-seated fixture | Changeover ≤25 min; first-off core-loss and concentricity data after every switch |
The pattern is that the binding stage tracks the mission’s dominant failure mechanism. FPV and high-speed platforms bind on winding and rotor balance because fine wire and high RPM expose insulation and unbalance first. Cinematic and inspection platforms bind on mating alignment because vibration is the visible failure. Agricultural platforms bind on coating and thermal verification because the environment attacks the insulation barrier. Heavy-lift platforms bind on stacking factor and press force because continuous torque depends on flux density and gap uniformity. Multi-model production binds on changeover discipline because the process, not the design, is what changes between runs.
A 5-Step Manufacturing Readiness Audit for Procurement Engineers
- Ask for the stage-by-stage control plan, not a capability statement. Request the control point at each of the five stages: burr and core loss at stage 1, tension and placement at stage 2, shaft tolerance and balance grade at stage 3, air gap and alignment at stage 4, and test coverage at stage 5. A supplier who can map all five is describing a production chain. A supplier who names only the winding machine and the test bench has described two stages out of five.
- Specify the stator core with value, standard, and location for every parameter. Write 0.20 mm non-oriented silicon steel, core loss ≤9.5 W/kg at 1.0 T / 400 Hz per IEC 60404-2 on the finished stack, B50 1.65–1.72 T, stacking factor ≥97%, concentricity ≤0.02 mm by vision, critical tolerance ±0.05 mm, burr height <0.03 mm by optical comparator, and C5 epoxy coating at >1400 V per ASTM D149 across −40°C to 180°C. A quote that omits the standard and the location leaves the interpretation to the supplier.
- Audit the winding control points with numbers, not adjectives. Require tension fluctuation within ±0.05 N, placement accuracy better than ±0.03 mm, and tooling alignment within ±0.02 mm. Ask for the tension controller resolution and the servo axis positioning data. Confirm the winding topology is concentrated and that the flyer architecture matches the slot orientation — external flyer for outward-facing outrunner slots, internal needle for inward-facing slots.
- Verify the mating stage as the air-gap gate. Ask for the alignment tolerance (published ≤0.05 mm), the press force and its control (±5%, 500–1,000 N), and the encoder feedback method. A supplier who cannot describe the mating control has not addressed the stage where the air gap — the dimension that decides vibration and torque ripple — is physically set.
- Require 100% end-of-line coverage and review the rejected unit. Specify Hi-Pot, surge waveform, three-phase resistance, and no-load (KV and current) testing on every unit, plus balancing verification at G2.5 or better, with test data bound to a serial number. Ask for a recent record showing a unit that failed surge testing and was rejected. A supplier with no rejected units is either perfect or not testing — and the rejected unit is the only evidence that the inspection process measures what it claims.
FAQ: Stages, Stator Core Priority, Lamination, Tension, Air Gap, EOL Tests, and Yield Cost
What are the main manufacturing stages for a motor de drone?
Manufacturing a brushless drone motor runs through five controlled stages: (1) stator core fabrication, where electrical steel laminations are stamped, stacked, and coated; (2) stator winding, where enameled copper is placed into the slots under controlled tension and terminated; (3) rotor assembly, where the shaft, magnets, and bearing seats are assembled and dynamically balanced; (4) stator-rotor mating, where the air gap is set under controlled force and alignment; and (5) end-of-line testing, where 100% of motors receive Hi-Pot, surge waveform, resistance, no-load, and balancing verification. Each stage carries a published tolerance, and a defect at any stage propagates forward — which is why the process chain, not the individual machine, is the unit of qualification.
Source: Reenives five-stage manufacturing framework; published BLDC stator winding process data; published drone assembly guidance (mating and testing).
Why does motor de drone manufacturing start with the stator core rather than the winding?
Because the stator core sets the physical and electromagnetic boundary that every later stage works inside. Its slot geometry determines whether an automated flyer or needle can enter and how much copper can be packed in. Its insulation coating determines how much winding tension the enamel can survive. Its burr height determines whether the coating is pierced during stacking and winding. Its concentricity determines half the air gap the mating stage must hold. A perfect winding on an out-of-tolerance core produces a motor that overheats or vibrates, and the failure will be attributed to the winding. That is why the core specification belongs in the same purchase decision as the winding process.
Source: Reenives stator core manufacturing analysis; published interlamination short mechanism analysis (burr piercing coating).
What lamination grade and core loss should a drone motor stator core specify?
For high-speed drone motors, 0.20 mm non-oriented silicon steel is the practical baseline. Reenives publishes ≤9.5 W/kg at 1.0 T / 400 Hz (typical 9.2 W/kg) measured by the Epstein frame per IEC 60404-2 on the finished stack, with B50 flux density 1.65–1.72 T, stacking factor ≥97%, concentricity ≤0.02 mm, burr height <0.03 mm, and C5 epoxy coating at >1400 V per ASTM D149 across −40°C to 180°C. A 0.35 mm grade runs at roughly 28–35 W/kg at the same test point. Because eddy-current loss scales with the square of lamination thickness, the 0.35 → 0.20 mm switch reduces iron loss by roughly 31% at the drone operating frequency, which becomes lower winding temperature and longer continuous torque headroom.
Source: Reenives 0.20 mm stator core specification (≤9.5 W/kg @ 1.0 T / 400 Hz, IEC 60404-2); published 0.35 mm comparison (28–35 W/kg); published eddy-current scaling relationship.
What winding tension and placement accuracy does a drone motor production line hold?
Published winding process data for drone stators specifies wire tension fluctuation within ±0.05 N and wire placement accuracy better than ±0.03 mm, with tooling, wire guides, and needles aligned to ±0.02 mm. These are not preferences — they are the parameters that prevent wire crossover, skipped turns, and enamel insulation damage. For drone outrunners with outward-facing slots, external flyer winding runs at 2,000–5,000 rpm. Concentrated winding is the default because it shortens end turns and reduces copper mass; after winding, vacuum impregnation reinforces the insulation barrier before assembly.
Source: Published BLDC stator winding process guide (tension ±0.05 N, placement ±0.03 mm, tooling ±0.02 mm, flyer 2,000–5,000 rpm, concentrated vs distributed); published assembly practice (vacuum impregnation).
How is the air gap set during stator-rotor mating in drone motor manufacturing?
The mating station sets the air gap physically, and it is where the accumulated tolerances of the core, the rotor, and the bearing seats either cancel or compound. Published drone assembly guidance specifies servo-driven mating with high-precision encoder feedback, alignment error held to ≤0.05 mm, and mating force controlled within ±5% of the design value — for example 1,000 N ± 50 N — to avoid gap distortion from over- or under-press. Published drone motor line data targets an air gap of 0.3 ± 0.05 mm with a 500–1,000 N press at ≤2 seconds per part. Post-mating sensors verify that no magnets or coils are missing before electrical testing.
Source: Published drone assembly guidance (servo mating, alignment ≤0.05 mm, force ±5%, sensor verification); published drone motor line data (air gap 0.3 ± 0.05 mm, press 500–1,000 N).
What end-of-line tests should every manufactured drone motor pass?
Every motor should undergo 100% electrical testing: Hi-Pot for insulation integrity, three-phase resistance for winding consistency measured by the four-wire method, and surge waveform testing for turn-to-turn short circuits. The no-load test covers no-load current, speed, noise, temperature rise, and three-phase balance, with out-of-tolerance units automatically rejected. Rotor balance is verified to G2.5 or better, and test data is bound to a serial number for traceability. The coverage question is decisive: a sampled test confirms the process average, while a 100% test protects the shipment. A supplier who cannot produce a rejected unit from the line is either perfect or not testing.
Source: Published drone motor testing platform data (100% no-load, KV and current screening, Hi-Pot, surge, balancing G2.5); published EOL testing framework (insulation, resistance, surge, 3-phase balance).
What does it cost in yield to manufacture a drone motor with an out-of-spec stator core?
More than the core costs. Published fully automatic drone motor line data reports 98% yield at 400 pcs/h, which means 8 motors per hour are scrapped — and each scrapped motor carries the cost of every upstream component plus every station it passed through. A stator core at the edge of the burr band produces a higher winding rejection rate than the winding station was designed to accommodate; a core at the edge of the concentricity band produces a wider air-gap distribution than the mating station can correct; a core at the edge of the stacking factor band produces lower flux density and fails the thermal test. The line’s yield is the product of its machine capability and its incoming part conformance, and the stator core is the incoming part that bounds the most stations.
Source: Published fully automatic drone motor line data (98% yield, 400 pcs/h); Reenives stator core specification (burr, concentricity, stacking factor).
Summary: Build the Core First, Then the Motor
How to manufacture motor de drone is not a winding-machine question. It is a five-stage process chain — stator core fabrication, winding, rotor assembly, mating, and end-of-line testing — in which the first stage sets the boundary for the other four. The published tolerances are concrete: burr <0.03 mm and core loss ≤9.5 W/kg at 1.0 T / 400 Hz per IEC 60404-2 on the finished stack at stage 1; tension ±0.05 N and placement ±0.03 mm at stage 2; shaft ~±0.005 mm and balance G2.5 at stage 3; air gap 0.3 ± 0.05 mm with alignment ≤0.05 mm and press 500–1,000 N at stage 4; and 100% Hi-Pot, surge, three-phase resistance, and no-load testing at stage 5.
The procurement takeaway is that the line’s yield is the product of its machine capability and its incoming part conformance — and the stator core is the incoming part that bounds the most stations. A core defect caught at stage 1 costs a core; the same defect caught at stage 5 costs a finished motor, and at 400 pcs/h with 98% yield, that is eight finished motors per hour. A supplier who can map all five stages, restate the stator core parameters with their standards and measurement locations, and produce a rejected unit from the end-of-line test is describing a production line. A supplier who quotes only the machine list is describing an equipment catalogue.
Sourcing stator cores for a motor de drone production programme?
Reenives publishes the stage-1 specification that the rest of your line depends on: 0.20 mm non-oriented silicon steel, core loss ≤9.5 W/kg at 1.0 T / 400 Hz per IEC 60404-2 on the finished stack, B50 1.65–1.72 T, stacking factor ≥97%, concentricity ≤0.02 mm by vision, critical tolerance ±0.05 mm, burr height <0.03 mm by optical comparator, and C5 epoxy coating at >1400 V per ASTM D149 across −40°C to 180°C, in 12N14P and related slot-pole configurations. Finished-stack reports, matched stator-rotor pairs, private mould development, and free samples are available for qualified engineering evaluations.
WhatsApp: +86-13377741885
Email: linda_reenives@163.com
Official website: www.reenives-bldcmotor.com
Dongguan Runlu Motor Technology Co., Ltd.
Reenives — Drone Motor One-Stop Solution Supplier
Reenives is a professional drone stator core manufacturer, founded in 2022. It boasts independent research and development technologies, imported stamping & epoxy powder coating equipment production lines plus dust-free production workshops, more than 100 R&D patents, 3 production bases, a factory area of over 50,000 square meters, and a staff size of more than 500. From production to sales, we support bulk purchasing, private mould development, and sample making, and can provide tailor-made perfect solutions for your production and usage scenarios. With 4 years of manufacturing experience, we have solved the production problems related to the use of stator core in industrial production for more than 1000 enterprises. We can ship globally (with complete export qualifications). Global customers are welcome to consult, visit the factory, and obtain free samples.
0.20 mm silicon steelCore loss ≤9.5 W/kg @ 1.0 T / 400 HzB50 1.65–1.72 TStacking factor ≥97%Concentricity ≤0.02 mmBurr <0.03 mmC5 epoxy >1400 V12N14P · 9N12P · 18N24P · 24N28PGlobal export qualifications
UAV Motors Guidance 2027
Size of Agriculture Drone Motor Stator
Related Article