What is Motor and Stator?

Motor and Stator — Why the Stationary Core, Not the Spinning Bell, Decides Whether a Drone Holds Hover
A drone motor fails on the bench in two ways that look identical to the operator: it loses thrust, or it overheats. The root cause in both cases is rarely the propeller or the ESC. It is the motor and stator relationship — specifically, the stator core’s inability to generate torque efficiently at the commanded current, or to move the resulting heat out of the winding before the insulation class ceiling is crossed. In a UAV BLDC outrunner, the stator is the heaviest single component, the primary magnetic flux path, and the component where both iron loss (in the steel) and copper loss (in the windings it carries) converge. Yet it is often specified as a dimensional envelope — outer diameter and stack height — while the variables that actually govern thermal survival are left to the supplier’s default process. This guide is written for drone motor engineers and B2B buyers who need to treat motor and stator as a coupled electromagnetic and thermal system, not two parts on a bill of materials.
Table of Contents
- What Is Motor and Stator?
- Radial vs. Axial, Slotted vs. Slotless: Which Stator Architecture Fits UAV Propulsion?
- Parameters That Separate a Usable Stator Core from a Thermal Liability
- Where Motor and Stator Performance Shows Up in UAV Propulsion
- Selection Checklist: Five Steps Before You Approve a Stator Core Spec
- FAQ: Motor and Stator Procurement Questions
- Summary & CTA
What Is Motor and Stator?
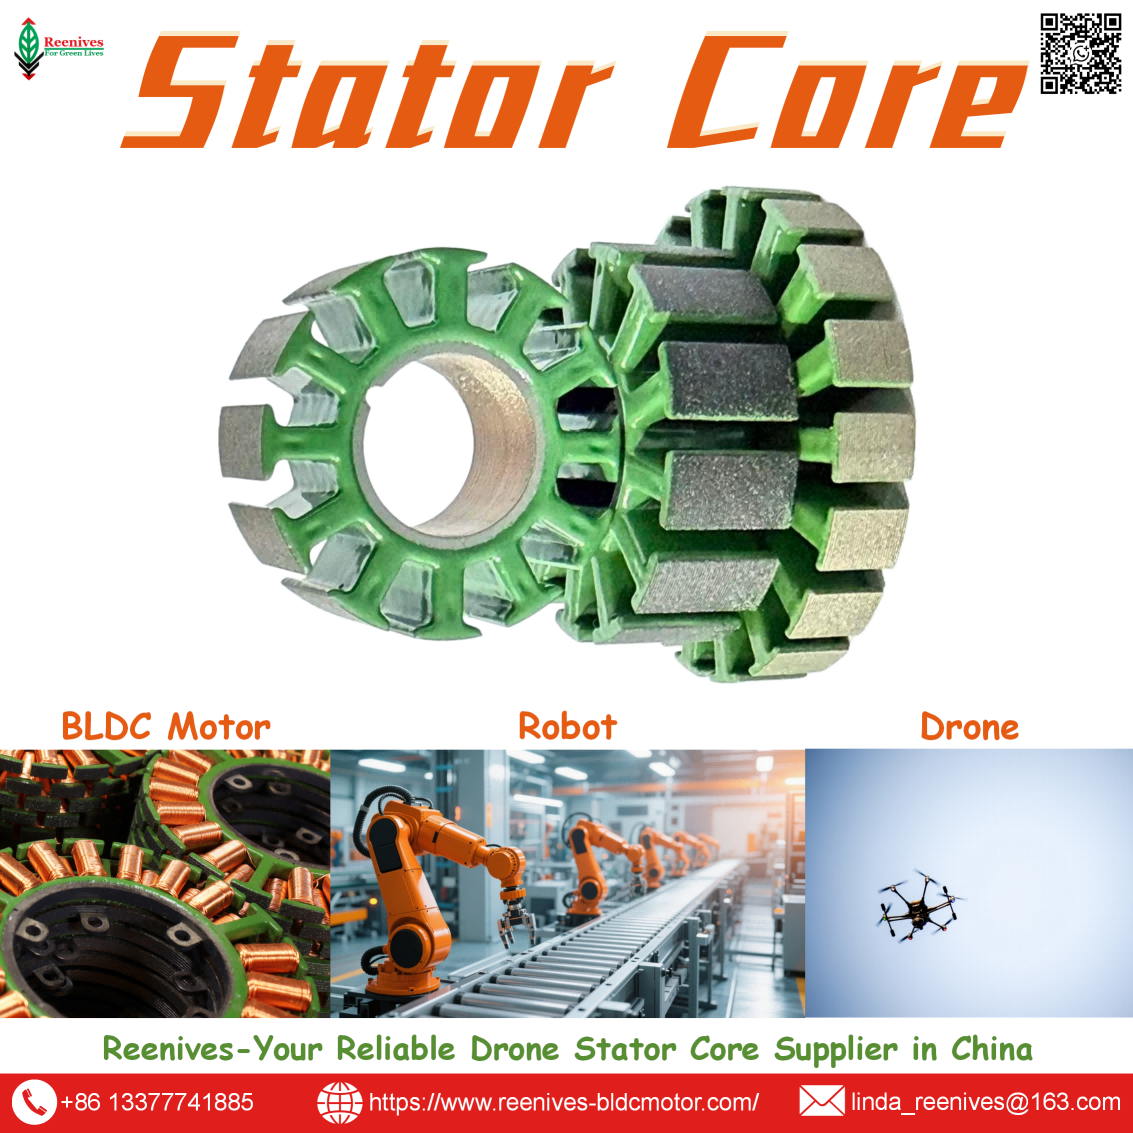
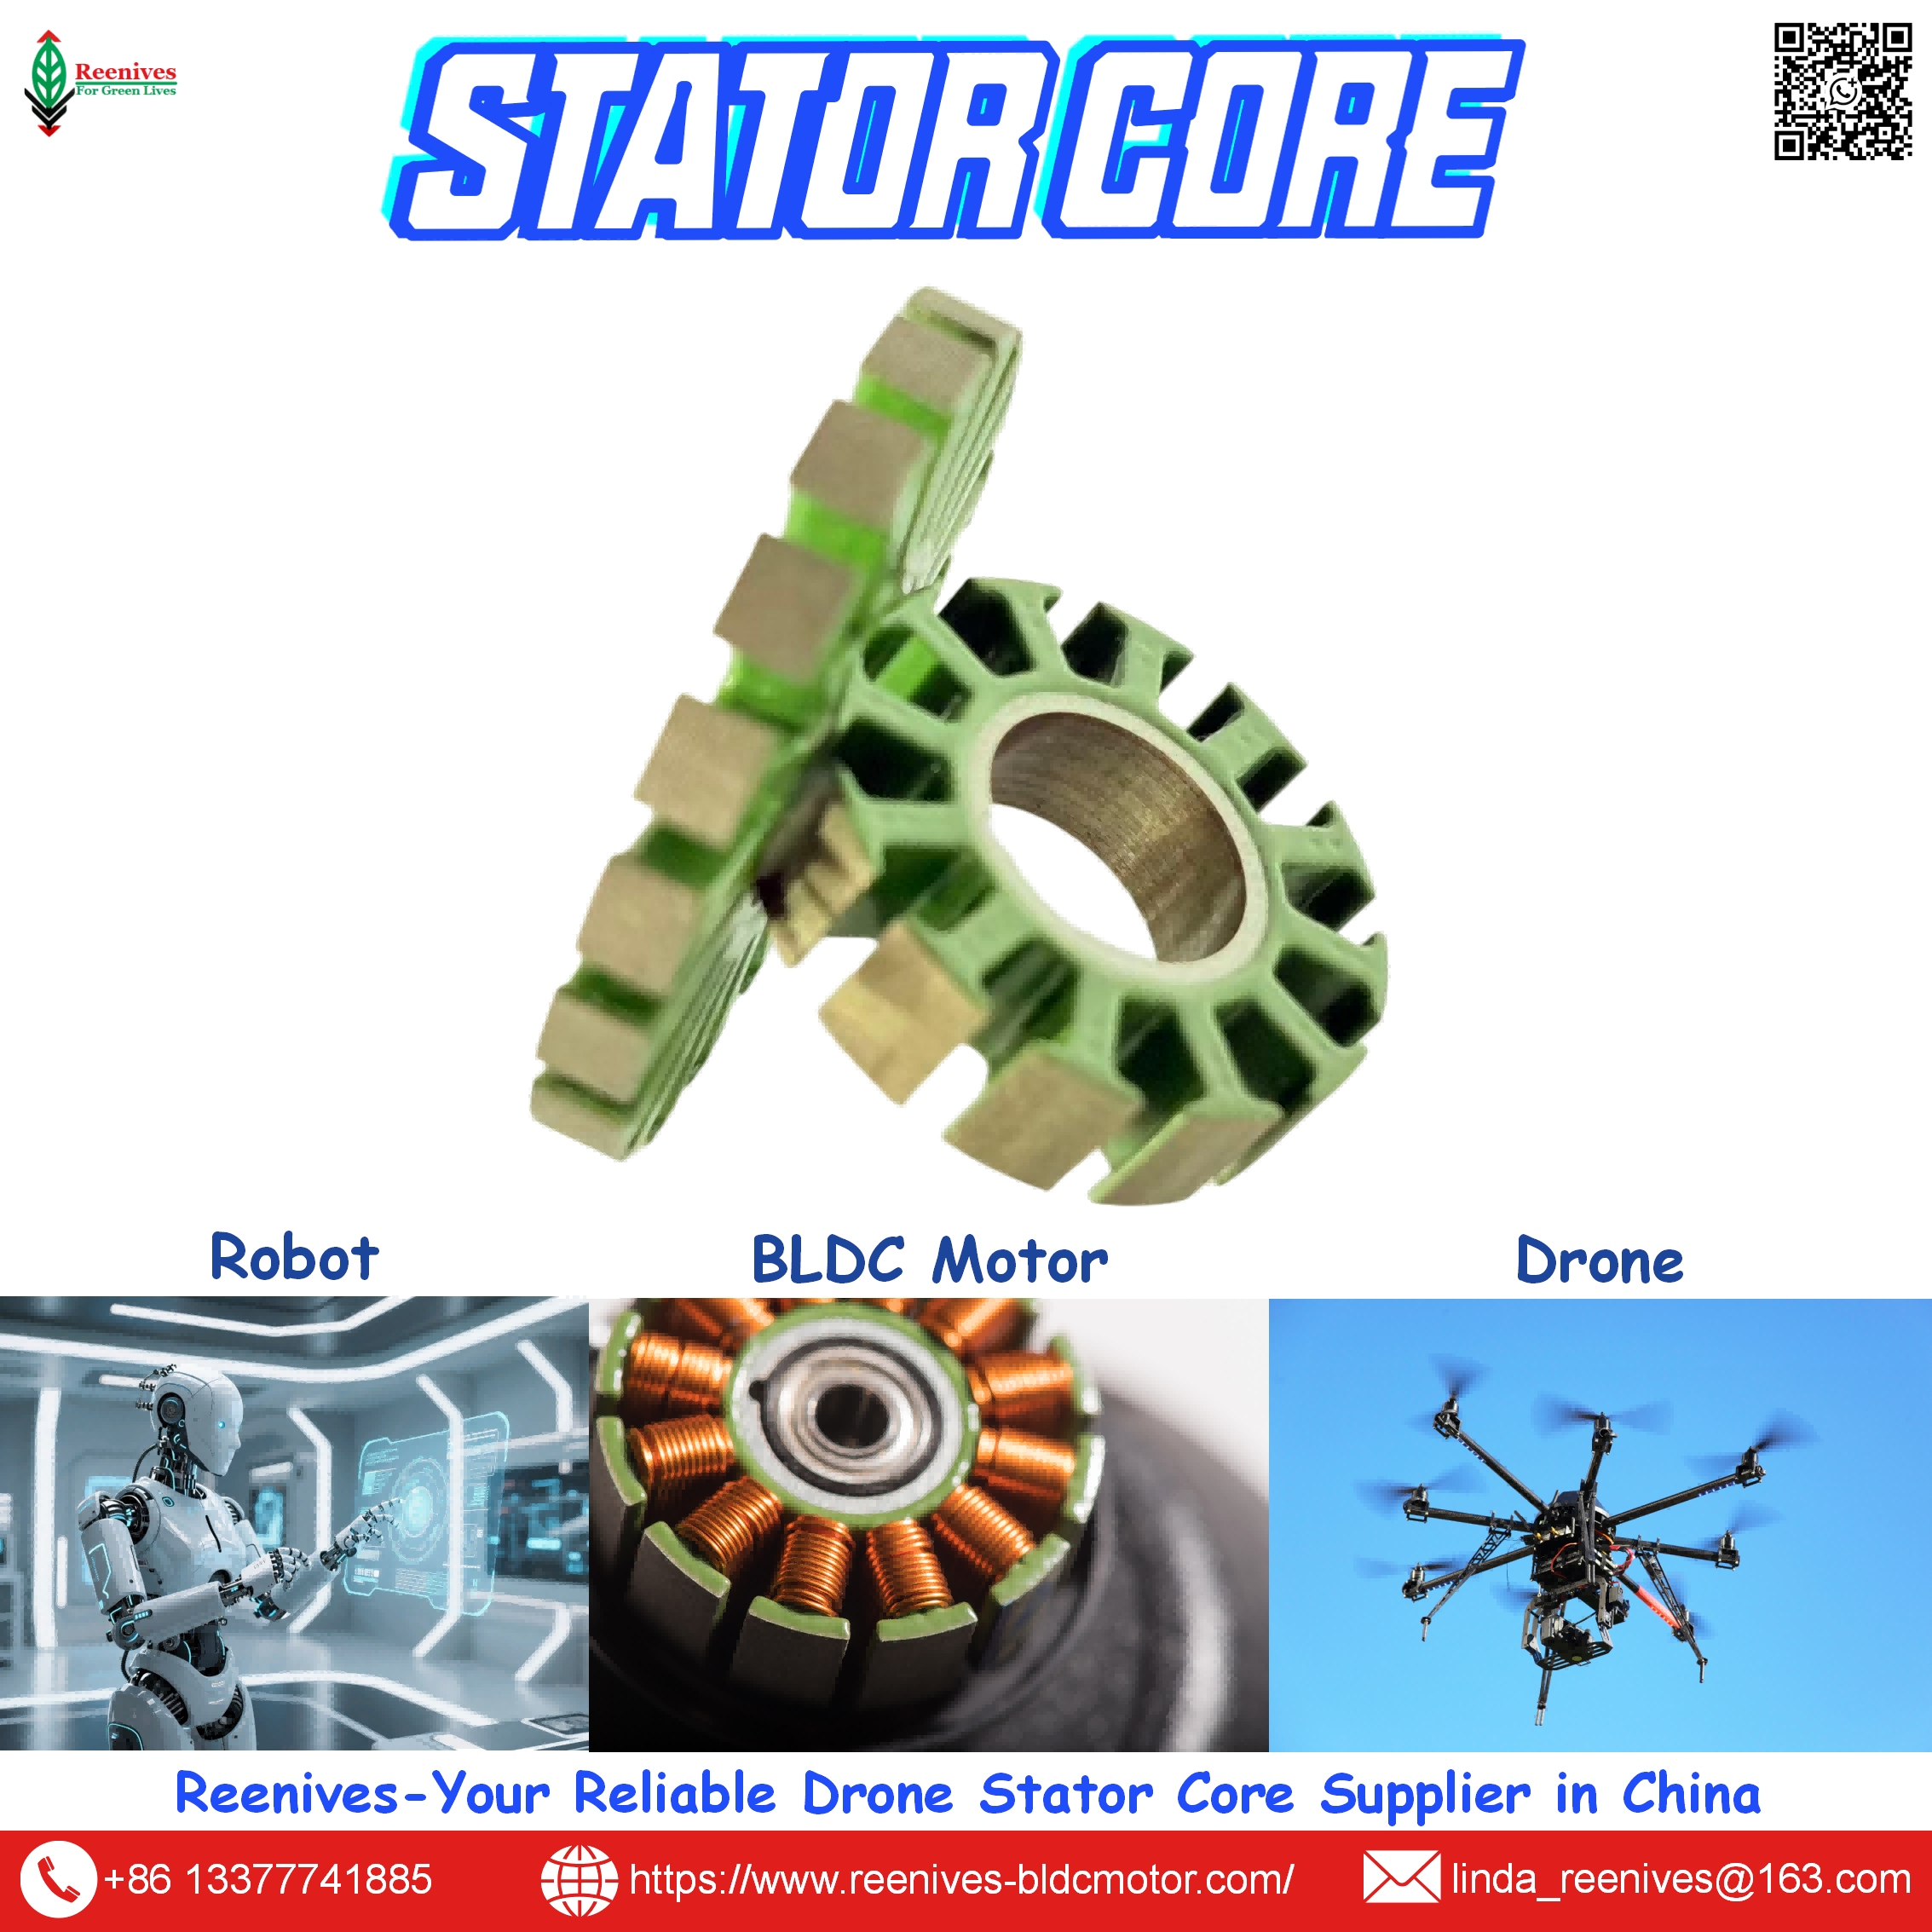
Motor and stator describes the functional pair at the heart of every rotating electrical machine. The motor is the complete assembly that converts electrical energy into mechanical rotation. The stator is the stationary electromagnetic structure inside that motor — in a drone BLDC outrunner, the laminated steel core with copper windings, mounted on the fixed arm, surrounded by a rotating bell that carries the permanent magnets (the rotor). The stator does not spin, but it produces the rotating magnetic field that drags the rotor around with it.
The relationship matters because the stator performs two jobs simultaneously, and those jobs compete for the same thermal budget:
| Stator Function | Physical Role | Drone-Specific Consequence |
|---|---|---|
| Magnetic flux path | Provides a low-reluctance path for the field that interacts with the rotor magnets | Sets torque per amp — the thrust available for a given current command |
| Heat exchanger | Absorbs copper loss from the windings and iron loss from its own laminations, conducts heat toward the housing | Sets the continuous current rating — the number that actually constrains payload and flight time |
A stator sized only to the motor’s “max current” label is not sized for a drone. The max current specification on a UAV motor is usually a burst rating; the true limit is the winding insulation temperature class after thermal steady state, and the stator core is the component that determines how quickly that limit is reached.
Radial vs. Axial, Slotted vs. Slotless: Which Stator Architecture Fits UAV Propulsion?
Stator architecture for UAV motors divides along two independent axes: flux direction (radial vs. axial) and slot presence (slotted vs. slotless/coreless). The choice is dictated by whether the dominant constraint is torque density at hover, iron loss at high speed, or axial length and weight.
Radial flux, slotted stator cores are the incumbent architecture for multirotor drones. The stator is a cylindrical iron core with slots carrying concentrated windings; the rotor surrounds or sits inside it. The iron is structurally essential — without it, air-gap reluctance would be too high and torque density would collapse. The teeth create a direct conduction path from the hot winding bundle into the core and housing, which is why slotted radial stators remain the practical default for sustained hover and climb, where copper loss dominates. The trade-offs are cogging torque and tooth-tip iron loss at the high electrical frequencies UAV motors operate at.
Radial flux, slotless stator cores eliminate the teeth. The winding is a self-supported cylinder in the air gap, so iron loss is dramatically reduced at high speed and cogging torque is virtually eliminated. A 4 kW-class drone propulsion study concluded that a slotless stator with a Halbach magnet configuration achieves high power density and sinusoidal back EMF — attributes that matter when the mission profile is dominated by high-speed cruise. The trade-off is lower torque density and a winding that relies more heavily on potting and the stator body for heat extraction, because there is no tooth conduction path.
Axial flux stator cores represent the third architecture, and the one with the steepest engineering trade-offs for weight-critical UAVs. In an axial flux motor, flux travels parallel to the rotation axis through a flat disc-shaped gap, and the active magnetic interaction covers the full annular disc area rather than a narrow cylindrical shell. This geometry produces a higher torque constant per unit mass and scales differently: radial flux flux area scales as diameter × length, while axial flux scales as diameter squared — doubling the diameter quadruples the flux area. Power-to-weight ratio for axial flux is reported at 2–5× radial in weight-critical applications, and axial length is very short. Coreless axial flux variants (including PCB-wound stators) remove core losses entirely and eliminate torque ripple, making them attractive for drone and eVTOL propulsion. The penalties are high air-gap sensitivity — tight tolerances are mandatory — and manufacturing complexity and unit cost at volume that remain higher than mature radial-flux production.
| Architecture | Dominant UAV Fit | Thermal Advantage | Primary Penalty |
|---|---|---|---|
| Radial slotted | Heavy-lift, agricultural, cargo multirotors; sustained hover | Tooth conduction path from winding to housing | Cogging torque; tooth-tip iron loss at high frequency |
| Radial slotless | High-speed cruise, precision inspection, gimbal systems | Low iron loss at source; negligible cogging | Lower torque density; winding heat trapped without teeth |
| Axial flux (coreless) | Weight-critical long-endurance UAV, eVTOL, high-power-density platforms | No core loss in coreless variants; short axial length | Tight air-gap tolerance; higher unit cost at volume |
For most 5-inch to heavy-lift multirotor platforms, radial slotted remains the baseline. Axial flux enters the specification when axial length and weight are the binding constraints and the volume justifies the tolerance and cost burden.
Parameters That Separate a Usable Stator Core from a Thermal Liability
Specifying the stator half of a motor and stator pair requires four parameters that directly control iron loss, effective magnetic steel, and air-gap magnetic performance. The values below are drawn from published material data, supplier manufacturing specifications, and UAV propulsion benchmarks — use them as a review baseline, not a substitute for prototype validation on your duty cycle.
| Parameter | Practical UAV Baseline | Consequence If Ignored |
|---|---|---|
| Lamination thickness | 0.20 mm for high-speed drone stators; 0.35 mm only for low-speed, cost-driven designs | Thicker steel → severe eddy-current penalty at UAV frequencies → continuous core heating |
| Iron loss @ 400 Hz, 1.0 T | ≤ 10–14 W/kg for 0.20 mm grades; supplier data ≤ 8.9 W/kg achievable | High-loss steel consumes thermal margin before copper loss is counted |
| Stacking factor | ≥ 98% for well-controlled thin laminations | Low factor → less effective steel → higher current for same torque |
| Bore / air-gap tolerance | ±0.05 mm critical dimensions; 0.2–1.0 mm air gap | Eccentric or oversized gap → flux loss, higher copper loss, vibration |
| Continuous power density (system context) | 3 kW/kg mainstream; 4–5 kW/kg high-end UAV | Peak-density specification without continuous validation → thermal derating in flight |
Where Motor and Stator Performance Shows Up in UAV Propulsion
The stator is not a passive structural spacer. It determines whether the propulsion system can sustain a hover, complete a transition, or survive a hot-day sortie. As payloads and endurance requirements climb, the continuous current rating — which is a stator thermal limit — becomes the constraint that payload calculations must respect.
Sustained hover and thermal steady state. In hover, current is roughly constant and the stator reaches thermal steady state within minutes. A stator with high iron loss at hover electrical frequency heats continuously, even before copper loss is considered. Verified testing on a 3110-class brushless drone motor showed that a 0.20 mm stator core delivered 12% higher torque density and 9°C lower winding temperature after a 10-minute hover compared with the conventional alternative. That is not a datasheet refinement — it is usable hover time and payload margin.
Throttle transients and burst ratings. A UAV motor’s “max current” specification is usually time-limited. Copper loss is quadratic in current, and the stator’s thermal mass and conduction path determine whether the next burst begins from an already-elevated baseline. A stator with low iron loss and a high stacking factor preserves thermal headroom between bursts; a lossy core consumes that headroom passively at every RPM.
High-ambient and agricultural UAV duty. Agricultural spraying drones and inspection platforms often operate above 35°C ambient, where the stator-to-ambient delta is reduced. The same motor and stator pair that holds insulation limits in a 25°C lab can exceed them in the field. Stator selection must use worst-case ambient, not nominal test conditions — and the stator’s iron loss at that operating point is part of the heat load.
Selection Checklist: Five Steps Before You Approve a Stator Core Spec
- Define continuous current, worst-case ambient, and duty cycle before stator dimensions. The familiar four-digit motor size (e.g., 2812) describes stator diameter and stack height, but thermal survival is set by continuous current, burst duration, ambient temperature, and airflow. Specify these first; the dimensional envelope follows from the thermal and magnetic requirement.
- Calculate electrical frequency at maximum continuous RPM and require iron-loss data at that frequency. Use fe = RPM × (poles/2) / 60. A 14-pole motor at 10,000 rpm runs at approximately 1,167 Hz; a 40-pole motor at the same speed runs at approximately 3,333 Hz. If a supplier can only provide 50/60 Hz loss data, the stator is not specified for UAV duty. Ask for W/kg iron-loss curves at the actual operating frequency and flux density.
- Choose lamination thickness and stacking factor together. For high-speed drone stators, evaluate 0.20 mm thin silicon steel as the baseline; step to thicker gauges only if loss modeling at the target RPM confirms thermal margin. Pair thickness with a specified stacking factor (≥ 98% for thin laminations) — a thin lamination with a poor stack factor gives back much of the loss benefit through reduced effective steel.
- Specify bore diameter, air gap, and concentricity as a matched set with the rotor. Require ±0.05 mm on critical stator dimensions and a defined air-gap budget (typically 0.2–1.0 mm for drone motors). For axial flux architectures, confirm the axial and radial tolerance stack explicitly; the disc geometry is less forgiving than radial flux. Require air-gap concentricity data (TIR) in PPAP documentation, not just a nominal bore dimension.
- Validate with hot-spot measurement in the actual mounting and airflow condition. A thermistor on the core or a thermal camera reading on the bell does not give the winding hot-spot temperature. Require winding resistance-based hot-spot estimation or embedded thermocouple data at continuous current in the worst-case ambient. The acceptance criterion is hot-spot temperature within the insulation class after thermal steady state — not a calculated efficiency or an averaged case temperature.
FAQ: Motor and Stator Procurement Questions
Q1: Is 0.20 mm lamination thickness always better than 0.35 mm for a drone stator?
For high-speed drone motors, 0.20 mm is the practical baseline because thinner laminations limit eddy-current circulation, cutting eddy-current loss by approximately 67% and core loss by up to 40% compared with 0.35 mm at equal flux density. However, thinner steel requires more laminations for the same stack height and increases stamping and handling cost. For low-speed, cost-constrained designs below roughly 3,000 RPM, 0.35 mm may remain acceptable. The decision should be made against measured iron loss at your maximum continuous electrical frequency and flux density, not against a generic material grade.
Q2: What stacking factor should I specify for a drone stator core?
For thin, well-controlled UAV laminations, specify a stacking factor of ≥ 98% with interlocked or self-bonded stacks. Industry benchmarks for conventional stacks sit at 96–97%, and the difference matters: a low stacking factor means less magnetic steel for the same stack height, which increases reluctance, forces higher current for the same torque, and adds copper loss to the thermal load. Confirm the stacking factor measurement method and include it in the PPAP documentation alongside stack height.
Q3: What air gap and bore tolerance should I specify between the stator and rotor for a drone BLDC motor?
For drone brushless stators, specify ±0.05 mm on critical bore and rotor outer diameter dimensions, with a typical air gap of 0.2 mm to 1.0 mm depending on motor size and rotor design. A smaller gap increases flux and torque density but demands tighter concentricity and bearing stiffness; a larger gap tolerates manufacturing variation but reduces flux and increases current for the same torque. Specify the gap and air-gap concentricity (TIR) together, and for axial flux architectures confirm the axial tolerance stack explicitly — the disc geometry is less forgiving than radial flux.
Q4: Does axial flux always beat radial flux for drone stators?
No. Axial flux offers 2–5× the power-to-weight ratio of radial flux in weight-critical applications and scales favorably with diameter, and coreless axial flux variants eliminate core loss and cogging torque entirely. But axial flux demands tight air-gap tolerances and carries higher unit cost at volume than mature radial-flux production. For most 5-inch to heavy-lift multirotors where radial length is not the binding constraint, radial slotted remains the lower-risk, lower-cost baseline. Axial flux is the right choice when axial length and weight are the primary constraints and the production volume justifies the tolerance and cost burden.
Q5: What continuous power density should I use to frame a stator specification?
For UAV motors under 30 kW, the 2025 industry mainstream continuous power density is 3 kW/kg, with high-end platforms at 4–5 kW/kg requiring high-grade magnets, lightweight housings, and direct cooling. Values above 6 kW/kg remain experimental. Use these as system-level context, not as a stator-only guarantee: a stator specified against a peak-density headline without a continuous thermal validation plan will not deliver the continuous thrust the airframe needs. The acceptance criterion remains hot-spot temperature within the insulation class after thermal steady state.
Summary & CTA
Motor and stator is not two components on a drawing. It is a coupled electromagnetic and thermal system where the stationary core decides whether the spinning rotor receives the flux it needs at a current the winding can survive. Lamination thickness, stacking factor, air-gap tolerance, and architecture choice — radial slotted, radial slotless, or axial flux — determine whether the core generates manageable iron loss at UAV frequencies and whether the heat from the windings it carries can reach the housing before the insulation class ceiling is crossed. If you are specifying a stator core for a new UAV platform or qualifying a second source, bring us your continuous current, maximum RPM, slot/pole combination, worst-case ambient, and air-gap budget.
Reenives — Drone Motor Stator Core One-Stop Solution Supplier
🌐 Website: www.reenives-bldcmotor.com
📱 WhatsApp: +86-13377741885
✉️ Email: linda_reenives@163.com
Send your stator dimensions, continuous current, maximum RPM, and air-gap target — we will return a stator core proposal with lamination thickness, stacking factor, bore tolerance, and a thermal validation plan aligned with your duty cycle.
Dongguan Runlu Motor Technology Co., Ltd.
About Reenives
Reenives is a professional drone stator core manufacturer, founded in 2022. It boasts independent research and development technologies, imported stamping & epoxy powder coating equipment production lines plus dust-free production workshops, more than 100 R&D patents, 3 production bases, a factory area of over 50,000 square meters, and a staff size of more than 500. From production to sales, we support bulk purchasing, private mould develop, and samples making, and can provide tailor-made perfect solutions for your production and usage scenarios. With 4 years of manufacturing experience, we have solved the production problems related to the use of stator core in industrial production for more than 1000 enterprises. We can ship globally (with complete export qualifications). Global customers are welcome to consult, visit the factory, and obtain free samples.
Social & Discoverability: Reenives / Dongguan Runlu Motor Technology Co., Ltd. — search for “Reenives drone stator core” and “Reenives motor and stator” on LinkedIn and Google to verify our manufacturing footprint, thin-lamination capability, and UAV stator core case references.
What is DC Generator Stator?
What is Electric Motor Stator?
Related Article