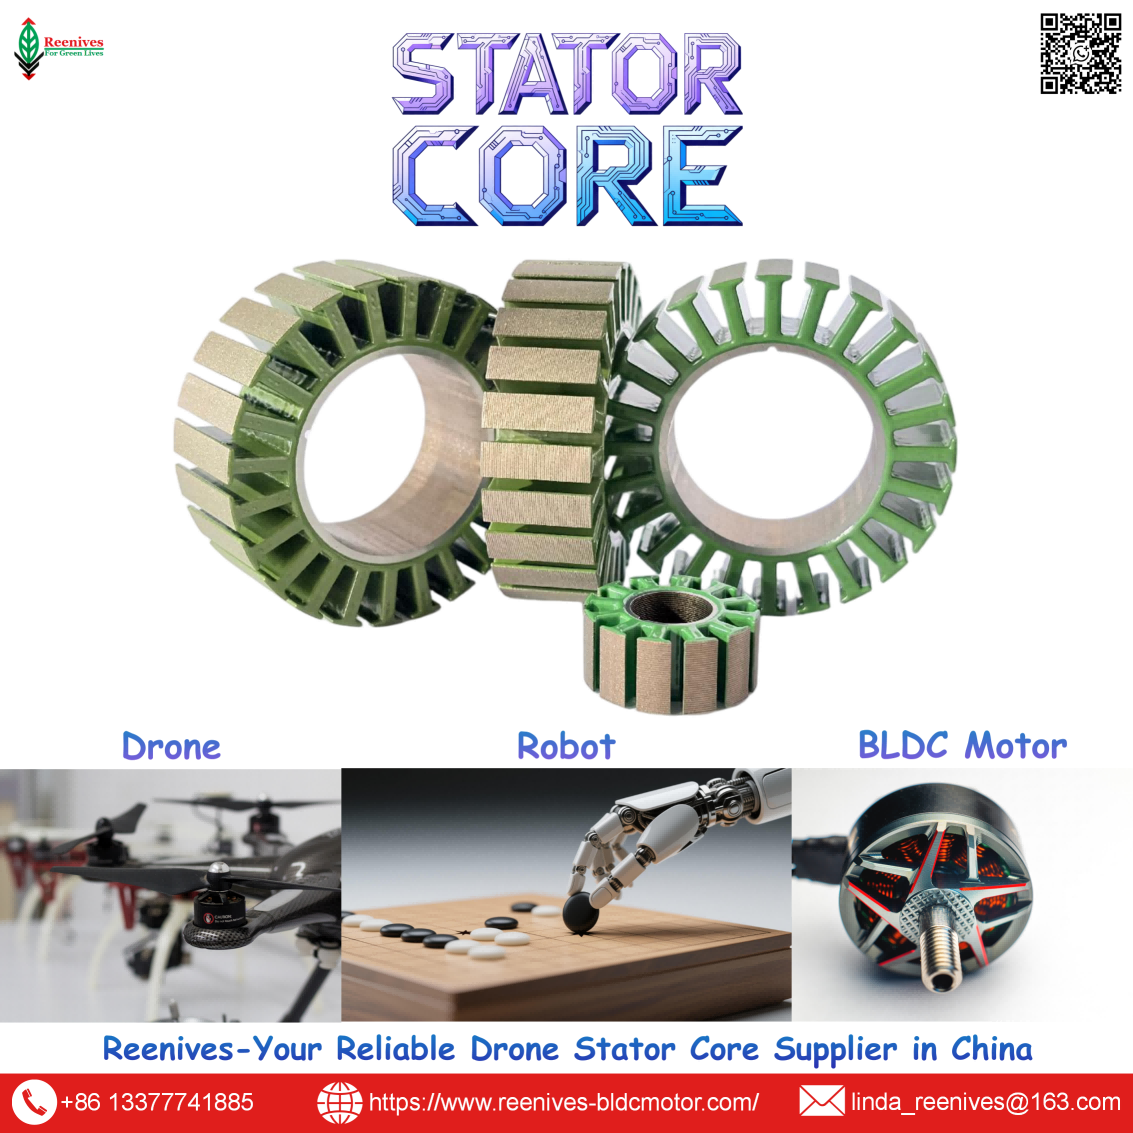
What is Brushless Drone?

What is a Brushless Drone? The BLDC Motor and Stator Core That Define Thrust, Endurance, and Thermal Margin
Most brushless drone problems are not flight-controller tuning problems. They are motor specification problems that were locked in before the first flight. The quad hovers, but the motors run hot. Endurance falls short of the battery calculation. Thrust sags after a few minutes of aggressive flying. The ESC logs show current spikes that do not match the bench data. In almost every case, the root cause sits in the brushless motor’s electromagnetic design — specifically in the stator core that converts electrical input into magnetic flux, and in the KV rating that decides how that flux is traded for RPM versus torque.
A brushless drone is defined by its propulsion motors, and those motors are not commodity parts. Published data shows brushless efficiency at 85–92% versus roughly 60–80% for brushed motors. The same sources show that KV is a torque-speed trade, not a quality score: high KV suits small propellers and racing, low KV suits large propellers and heavy-lift, and mismatching the two causes either low thrust or excessive current draw. And the stator core underneath all of that has a measurable loss profile: 0.20 mm laminations at roughly 10–14 W/kg at 1.0 T / 400 Hz, versus 0.35 mm laminations at roughly 28–35 W/kg — a difference that becomes winding temperature and lost flight time at drone operating frequencies.
This guide answers the long-tail question at the level a propulsion engineer or procurement lead needs: the BLDC definition and how the motor produces thrust, the KV and slot-pole families that define drone motor behavior, the published core-loss and thermal parameters with their standards, the mission profiles where each specification binds, and a five-step selection workflow that turns a motor datasheet into a purchase specification. Every figure below is traceable to a published source or a named measurement standard.
In this guide — jump to the section your project needs:
- What Is a Brushless Drone? The BLDC Definition and the Energy-Conversion Chain
- Brushless Drone Motor Configurations: Outrunner, Inrunner, and Slot-Pole Families
- Published Parameters: KV, Core Loss, Lamination Thickness, B50, Coating, and Magnet Grade
- Application Profiles: Which Motor Parameter Binds Which Drone Mission
- A 5-Step Brushless Motor Selection Workflow for Drone Platforms
- FAQ: Definition, KV, Lamination Thickness, Stator Core Specifications, Overheating, and Magnet Grade
- Summary: Specify the Motor, Not Just the Frame
What Is a Brushless Drone? The BLDC Definition and the Energy-Conversion Chain
A brushless drone is an unmanned aircraft whose propulsion comes from brushless DC (BLDC) motors. The defining difference from a brushed motor is the commutation method. A brushed motor uses a mechanical commutator and carbon brushes to switch current in the rotating armature. A BLDC motor removes that contact entirely: permanent magnets sit on the rotor, three-phase windings sit on the stator, and an external electronic speed controller (ESC) switches current through the stator phases in sequence to create a rotating magnetic field that pulls the rotor magnets around.
The energy-conversion chain is the definition in motion. The battery supplies DC power. The ESC converts that DC into three-phase current and applies it to the motor windings in a precise sequence, creating a rotating magnetic field. The stator’s laminated core concentrates that magnetic flux. The rotor’s permanent magnets are pulled by the rotating field, producing torque. The rotor drives the propeller directly in an outrunner configuration, and the propeller accelerates air to produce thrust. Every stage has a loss, and the two that matter most for a drone’s endurance are copper loss in the windings and iron loss in the stator core.
That last point is where the brushless drone definition becomes a specification problem. Iron loss has two components: hysteresis loss, proportional to frequency, and eddy-current loss, proportional to the square of both lamination thickness and electrical frequency (t²f²B²). A 14-pole motor at 15,000 RPM runs at an electrical frequency of 1,750 Hz, and at that frequency the eddy-current penalty for thick laminations is severe. The motor that looks adequate on a 50 Hz bench test can underperform in the air, because the air is where the frequency is high and the core loss becomes heat.
Procurement translation: “brushless drone” describes the propulsion architecture, not the performance level. Two drones can both be brushless and have very different endurance, thermal margin, and thrust consistency, because the BLDC category contains a wide range of KV ratings, stator geometries, lamination grades, and magnet specifications. The specification must name the motor-level parameters — KV, slot-pole, stator core grade and thickness, and the operating point — not the architecture label alone.
Brushless Drone Motor Configurations: Outrunner, Inrunner, and Slot-Pole Families
Brushless drone motors are classified along two axes that matter for selection: the rotor topology (outrunner versus inrunner) and the slot-pole combination inside the stator.
Outrunner versus inrunner
| Topology | Construction | Torque / Speed Character | Drone Role |
|---|---|---|---|
| Outrunner | External bell with magnets rotates around an internal stator | Higher torque at lower RPM; direct propeller mounting | Dominant for multirotor propulsion and direct-drive propellers |
| Inrunner | Rotor spins inside the stator | Lower inertia, faster dynamic response, higher speed capability | Gimbals and auxiliary motion functions where fast response matters |
The outrunner’s dominance in propulsion is not a preference; it is a consequence of the torque-speed requirement. A multirotor propeller needs relatively high torque at moderate RPM, and an outrunner’s larger diameter produces that torque without a gearbox. In outrunner motors, the stator coils are on the inside and the rotor spins around the outside, which is the more common configuration in drones. The rotor consists of permanent magnets, and the stator consists of the spokes of the motor with coils that create a magnetic field when current passes through them.
Slot-pole families: 12N14P and its alternatives
The slot-pole combination defines the electromagnetic structure inside the motor. A 12N14P motor has 12 stator slots and 14 rotor poles, and it is one of the most common outrunner configurations for drone and higher-torque applications. The slot count is divisible by three for balanced three-phase operation, and the unequal slot-to-pole ratio reduces cogging torque. The concentrated winding pattern commonly used with 12N14P is ABCABCABCABC.
| Slot-Pole | Slots | Poles | Character | Typical Drone Fit |
|---|---|---|---|---|
| 12N14P | 12 | 14 | Higher torque, low cogging, concentrated winding | FPV and multirotor propulsion; the workhorse configuration |
| 9N12P | 9 | 12 | Lightweight, higher speed bias | Small outrunners and lightweight builds |
| 24N28P | 24 | 28 | More slots, different torque-ripple profile | Larger outrunners and custom high-torque platforms |
Sources: Published outrunner slot-pole reference (12N14P common for higher-torque applications, ABCABCABC winding); Reenives custom geometry record (12N14P, 24N28P delivered for drone and eVTOL clients).
The practical selection rule is that 12N14P is the default for drone propulsion because it balances torque, cogging, and winding manufacturability. Other combinations are not upgrades or downgrades; they are different trade-offs. A 9N12P motor may be lighter and better suited to a small propeller; a 24-slot stator may be chosen for a larger outrunner where a different torque-ripple profile is acceptable. The slot-pole count must be matched to the stator core geometry and the rotor pole count, which is why a “12-slot stator” without a specified pole count is an incomplete specification.
Published Parameters: KV, Core Loss, Lamination Thickness, B50, Coating, and Magnet Grade
KV and the torque-speed trade
KV is the motor’s velocity constant — RPM per volt under no load — and the formula is RPM = KV × Voltage. For the same motor size, higher KV means more RPM but less torque; lower KV means more torque but lower RPM. Published ranges place high KV at 2000–4000+ (small propellers, racing), low KV at 300–1000 (large propellers, heavy-lift), and mid KV at 1000–2000 as the common range for 5-inch freestyle. The matching rule is equally published: pair high KV with small-diameter propellers and low KV with large-diameter propellers; mismatching causes either very little thrust or excessive current draw and overheating.
Lamination thickness and core loss: the stator-core parameter that decides heat
Iron loss has two components: hysteresis loss, proportional to frequency and the grade’s coercivity, and eddy-current loss, proportional to the square of both lamination thickness and frequency. In a 50 Hz industrial motor, thick laminations are tolerable. In a drone motor at 15,000 RPM, the electrical frequency is far higher and the eddy-current penalty becomes severe. Published comparison data is direct:
| Thickness | Typical Grade | Iron Loss @ 1.0 T / 400 Hz | Best Fit | Relative Cost |
|---|---|---|---|---|
| 0.35 mm | 35W300 / 35W270 | ~28–35 W/kg (published range) | Industrial servo ≤3,000 RPM, low-speed torque motors | Low |
| 0.20 mm | 20W1200H / 20W1500H; Reenives 0.20 mm grade | ~10–14 W/kg (published range); Reenives ≤9.6 W/kg (typical 9.2) | High-speed ≥8,000 RPM, UAV, FPV, frameless motors | High |
Sources: HIMAGNET lamination comparison (0.20 mm ~10–14 W/kg, best for UAV; 0.35 mm ~28–35 W/kg); Reenives 0.20 mm grade specification (≤9.6 W/kg typical 9.2, per IEC 60404-2).
The motor-level consequence is thermal. Reenives’ comparative data shows that moving from a 0.35 mm to a 0.20 mm core reduces core loss from ~14 W/kg to ≤9.6 W/kg (approximately 31% reduction), which in drone hover tests translated to 6–8% longer endurance and 15°C lower stator temperature. That thermal margin is the difference between a hover that holds its thrust curve and one that sags as the winding heats and resistance rises.
Stator core specifications that carry the loss performance
A stator core specification must name the measurement standard, not just the loss number. IEC 60404-2 defines the Epstein-frame method for specific total loss of electrical steel. Reenives publishes its 0.20 mm grade with a complete parameter set: core loss ≤9.6 W/kg (typical 9.2) at 1.0 T / 400 Hz, magnetic flux density B50 ≥1.69 T, thickness 0.20 mm ±0.008 mm, C5 epoxy coating at >1400 V dielectric strength per ASTM D149, burr height ≤0.03 mm, and operating temperature −40°C to 180°C (short peak 200°C). For drone-grade cores, concentricity ≤0.02 mm keeps the air gap uniform, and interlocked or bonded stacking holds the stacking factor that preserves the flux density the lamination grade was selected to provide.
The datasheet-versus-field gap: a motor can use “0.20 mm electrical steel” and still underperform if the stack is loose, the burr height is uncontrolled, or the coating does not survive thermal cycling. The lamination grade sets the potential; the stator core manufacturing process determines how much of that potential reaches the installed motor. That is why the procurement specification must name finished-stack core loss, burr control, stacking factor, and concentricity — not just the steel grade.
Magnet grade: strength versus temperature
The rotor magnets close the magnetic circuit, and their grade code carries two variables that are frequently conflated. The number is the maximum energy product (BHmax) in MGOe — the strength. The suffix letter is the coercivity class that sets the maximum operating temperature. Published tables define the classes: standard ≤80°C, M ≤100°C, H ≤120°C, SH ≤150°C, UH ≤180°C, EH ≤200°C, AH ≤230°C.
Published UAV motor thermal analysis notes that calculated magnet temperatures may reach only about 60°C in a benign flight cycle, but recommends at least a twofold temperature margin for real-world conditions including prolonged maximum thrust, elevated ambient, and limited cooling. That margin justifies N42SH (150°C) as a practical drone baseline rather than a standard grade capped at 80°C. N52 is stronger at room temperature but its maximum working temperature is even lower, which is why grade selection must follow the measured operating temperature, not the room-temperature number.
Application Profiles: Which Motor Parameter Binds Which Drone Mission
| Drone Mission Class | Typical Motor / KV | Binding Parameter | Specification to Write |
|---|---|---|---|
| FPV racing / freestyle | High KV (2000–4000+) · 5-inch class | Iron loss at high electrical frequency; KV–propeller match | 0.20 mm low-loss stator grade; KV matched to prop diameter; core loss ≤9.6 W/kg @ 1.0 T / 400 Hz |
| Cinematic / long-range | Mid KV (1000–2000) · 5–7 inch | Efficiency (g/W) and thermal margin at cruise | 0.20 mm grade; efficiency curve at cruise; concentricity ≤0.02 mm for vibration control |
| Agricultural spraying | Low KV (90–150) · large propellers | Continuous thermal margin; coating durability | C5 epoxy coating (>1400 V, −40°C to 180°C); 0.20 mm grade; finished-stack core loss report |
| Heavy-lift / logistics | Low KV (<100) · large diameter | Torque per amp and continuous thermal headroom | Stator volume and stacking factor; N42SH (150°C) magnet minimum; efficiency curve above 85% |
The pattern is that the binding parameter tracks the mission’s dominant loss mechanism. FPV racing binds on iron loss at high frequency and on the KV–propeller match, because a mismatch either starves thrust or overheats the motor. Cinematic and long-range bind on efficiency at cruise, because endurance is the product. Agricultural and heavy-lift bind on continuous thermal margin and coating durability, because the duty cycle is long and the environment is harsh. A motor specified only by KV has been specified on the variable that is easiest to quote and least sufficient to decide reliability.
A 5-Step Brushless Motor Selection Workflow for Drone Platforms
- Work backwards from thrust-to-weight, not forwards from a motor catalog. State the all-up weight, the number of motors, and the thrust-to-weight ratio the mission requires. Published UAV propulsion guidance emphasizes that motors, ESCs, and propellers form a system, and that proper design and tuning of the propulsion system are critical to achieving the desired performance for any aerial platform. A motor that looks efficient on a test stand can be undersized once the airframe and payload are included.
- Fix KV from the propeller diameter, then verify the efficiency at the cruise point. Use the published matching rule: high KV with small propellers, low KV with large propellers. Then check the efficiency curve at the throttle the mission actually uses. A motor that peaks efficiently at full throttle but cruises inefficiently is the wrong motor for an endurance platform.
- Specify the stator core grade and thickness against the electrical frequency, not the mechanical RPM. Calculate electrical frequency as RPM × pole pairs. For a 14-pole motor at 15,000 RPM, that is 1,750 Hz — well into the range where 0.35 mm laminations generate significant eddy-current loss. Specify 0.20 mm low-loss grade for high-frequency drone operation, and require core loss at a defined test point (1.0 T / 400 Hz) measured per IEC 60404-2 on the finished stack.
- Require the stator core manufacturing controls that preserve the grade’s potential. Name burr height (≤0.03 mm per Reenives specification), stacking factor, concentricity (≤0.02 mm for drone-grade cores), and coating class (C5 epoxy at >1400 V dielectric strength per ASTM D149). The lamination grade sets the loss ceiling; the stacking and burr control determine how much of that ceiling is achieved in the finished motor.
- Match the magnet temperature class to the measured operating temperature, with margin. Published UAV thermal analysis recommends at least a twofold temperature margin relative to calculated heating, which supports N42SH (150°C) as a practical baseline rather than a standard grade capped at 80°C. Audit the motor-level test data at the operating point, not the catalog headline: ask for the thrust table at the intended voltage and propeller, the efficiency curve across throttle, and the winding temperature at continuous cruise.
FAQ: Definition, KV, Lamination Thickness, Stator Core Specifications, Overheating, and Magnet Grade
What is a brushless drone, and how does the motor produce thrust?
A brushless drone is an unmanned aircraft whose propulsion comes from brushless DC (BLDC) motors. The motor has a fixed stator with copper windings and a rotating rotor lined with permanent magnets. An electronic speed controller (ESC) converts the battery’s DC power into three-phase current and switches it through the stator windings in a precise sequence, creating a rotating magnetic field that pulls the rotor magnets around. Because there is no mechanical commutator or brush contact, brushless motors avoid brush wear and achieve higher efficiency — published figures place brushless efficiency at 85–92% versus roughly 60–80% for brushed motors. That efficiency and RPM capability are why virtually all modern multirotor drones use brushless propulsion.
Source: Published BLDC operation and efficiency comparison for drone propulsion.
How does KV affect brushless drone performance, and how do I choose it?
KV is the motor’s velocity constant: RPM per volt under no load, so RPM = KV × Voltage. For the same motor size, higher KV means more RPM but less torque; lower KV means more torque but lower RPM. High KV (2000–4000+) suits small propellers and racing drones; low KV (300–1000) suits large propellers, heavy-lift, and long-range builds; mid KV (1000–2000) is the common range for 5-inch freestyle. The practical rule is to pair high KV with small-diameter propellers and low KV with large-diameter propellers. Mismatching the two causes either very little thrust or excessive current draw and overheating.
Source: Published KV–thrust–efficiency selection data for brushless drone motors.
How does lamination thickness in the stator core affect a brushless drone?
Eddy-current loss in the stator core is proportional to the square of both lamination thickness and electrical frequency (t²f²B²). In a drone motor running at hundreds to over a thousand hertz electrical, thick laminations generate significant eddy-current heat. Published data shows 0.20 mm grades at roughly 10–14 W/kg at 1.0 T / 400 Hz, versus 0.35 mm grades at roughly 28–35 W/kg. Reenives publishes ≤9.6 W/kg (typical 9.2 W/kg) for its 0.20 mm grade at the same test point, measured per IEC 60404-2. Moving from 0.35 mm to 0.20 mm reduces eddy-current loss by approximately 67% at the same flux density.
Source: HIMAGNET lamination comparison; Reenives 0.20 mm grade specification; published eddy-current proportionality (t²f²B²).
What stator core parameters should I specify for a brushless drone motor?
A complete stator core specification names the lamination thickness and grade (for example 0.20 mm low-loss non-grain-oriented silicon steel), the core loss at a defined test point measured per IEC 60404-2 on the finished stack, the stacking factor, the concentricity between stator bore and rotor outer diameter, the insulation coating class, and the burr height limit. Reenives publishes 0.20 mm grade at ≤9.6 W/kg at 1.0 T / 400 Hz, B50 ≥1.69 T, concentricity ≤0.02 mm, C5 epoxy coating at >1400 V dielectric strength per ASTM D149, and burr height ≤0.03 mm. These are the parameters that determine whether the stator delivers its rated flux density in the finished motor.
Source: Reenives 0.20 mm laminated core specification (IEC 60404-2, ASTM D149, GB/T 3655-2022).
Why does a brushless drone motor overheat or lose thrust over time?
Two failure paths dominate. The first is iron loss: thick laminations at high electrical frequency generate eddy currents that become heat in the stator, raising winding temperature and forcing the motor to derate before it reaches rated torque. Reenives’ comparative data shows that moving from a 0.35 mm to a 0.20 mm core reduces core loss from ~14 W/kg to ≤9.6 W/kg, which in drone hover tests translated to 6–8% longer endurance and 15°C lower stator temperature. The second path is magnet demagnetization: a standard-grade NdFeB magnet rated to ~80°C will lose field strength in a motor that runs hotter. Published UAV thermal analysis recommends N42SH (150°C) or higher when continuous load and limited cooling push magnet temperatures beyond the standard grade’s ceiling.
Source: Reenives comparative hover test data (6–8% endurance, 15°C reduction); published UAV thermal analysis recommending N42SH for temperature margin.
What NdFeB magnet grade should a brushless drone motor use?
The grade number is strength (BHmax in MGOe); the suffix letter is the coercivity class that sets maximum operating temperature. Standard grade: ≤80°C. SH: ≤150°C. UH: ≤180°C. EH: ≤200°C. Published UAV motor thermal analysis notes that calculated magnet temperatures may reach only 60°C in a benign flight cycle, but recommends at least a twofold temperature margin for real-world conditions including prolonged maximum thrust and elevated ambient. That margin justifies N42SH (150°C) as a practical drone baseline rather than a standard grade capped at 80°C. N52 is stronger at room temperature but carries an even lower temperature ceiling, which is why grade selection must follow the measured operating temperature, not the room-temperature number.
Source: Published NdFeB grade suffix table (standard ≤80°C, SH ≤150°C, UH ≤180°C); UAV motor thermal analysis recommending N42SH with twofold margin.
Summary: Specify the Motor, Not Just the Frame
What is a brushless drone? It is an aircraft whose thrust comes from electronically commutated BLDC motors — and the definition only becomes useful for procurement when it is expanded into the parameters that decide whether the aircraft hovers efficiently or overheats. KV sets the torque-speed trade; the slot-pole combination sets the electromagnetic structure; lamination thickness sets the iron loss at the electrical frequency the motor actually runs at; and the stator core manufacturing controls determine how much of the grade’s potential reaches the finished motor.
The published numbers are concrete. Brushless efficiency is 85–92% versus roughly 60–80% for brushed motors. KV ranges from 2000–4000+ for racing to 300–1000 for heavy-lift. Iron loss at 1.0 T / 400 Hz runs roughly 28–35 W/kg for 0.35 mm laminations and 10–14 W/kg for 0.20 mm, with Reenives publishing ≤9.6 W/kg for its grade measured per IEC 60404-2. And the 0.35 mm → 0.20 mm switch reduces eddy-current loss by approximately 67% at the same flux density, which in hover testing translated to 6–8% longer endurance and 15°C lower stator temperature. The magnet side is equally concrete: N42SH at 150°C provides the twofold temperature margin that published UAV thermal analysis recommends over a standard grade capped at 80°C.
The selection takeaway is that the motor is a system component, not a commodity line item. A drone platform that specifies KV but not the stator core grade, or the thrust table but not the thermal test condition, has left the endurance and reliability outcomes to the supplier’s default. The specification that prevents overheating and short flight time is the one that names the stator core’s finished-stack loss, the lamination thickness, the stacking factor, and the concentricity — because those are the parameters that turn a brushless motor into a brushless drone that holds its performance.
Sourcing stator cores for a brushless drone motor programme?
Reenives manufactures precision laminated stator and rotor cores for brushless drone motors: 0.20 mm low-loss non-grain-oriented silicon steel, core loss ≤9.6 W/kg (typical 9.2) at 1.0 T / 400 Hz measured per IEC 60404-2, B50 ≥1.69 T, C5 epoxy coating at >1400 V dielectric strength per ASTM D149, concentricity ≤0.02 mm, and burr height ≤0.03 mm. Matched stator-rotor pairs, private mould development, and free samples are available for qualified drone and BLDC motor programmes.
WhatsApp: +86-13377741885
Email: linda_reenives@163.com
Official website: www.reenives-bldcmotor.com
Dongguan Runlu Motor Technology Co., Ltd.
Reenives — Drone Motor One-Stop Solution Supplier
Reenives is a professional drone stator core manufacturer, founded in 2022. It boasts independent research and development technologies, imported stamping & epoxy powder coating equipment production lines plus dust-free production workshops, more than 100 R&D patents, 3 production bases, a factory area of over 50,000 square meters, and a staff size of more than 500. From production to sales, we support bulk purchasing, private mould development, and sample making, and can provide tailor-made perfect solutions for your production and usage scenarios. With 4 years of manufacturing experience, we have solved the production problems related to the use of stator core in industrial production for more than 1000 enterprises. We can ship globally (with complete export qualifications). Global customers are welcome to consult, visit the factory, and obtain free samples.
0.20 mm NO silicon steelCore loss ≤9.6 W/kg @ 1.0 T / 400 HzB50 ≥1.69 TIEC 60404-2 verifiedC5 epoxy · >1400 VConcentricity ≤0.02 mmBurr ≤0.03 mmMatched stator + rotor pairsGlobal export qualifications
Reenives: Global Leading Drone Motor Parts Supplier
Related Article