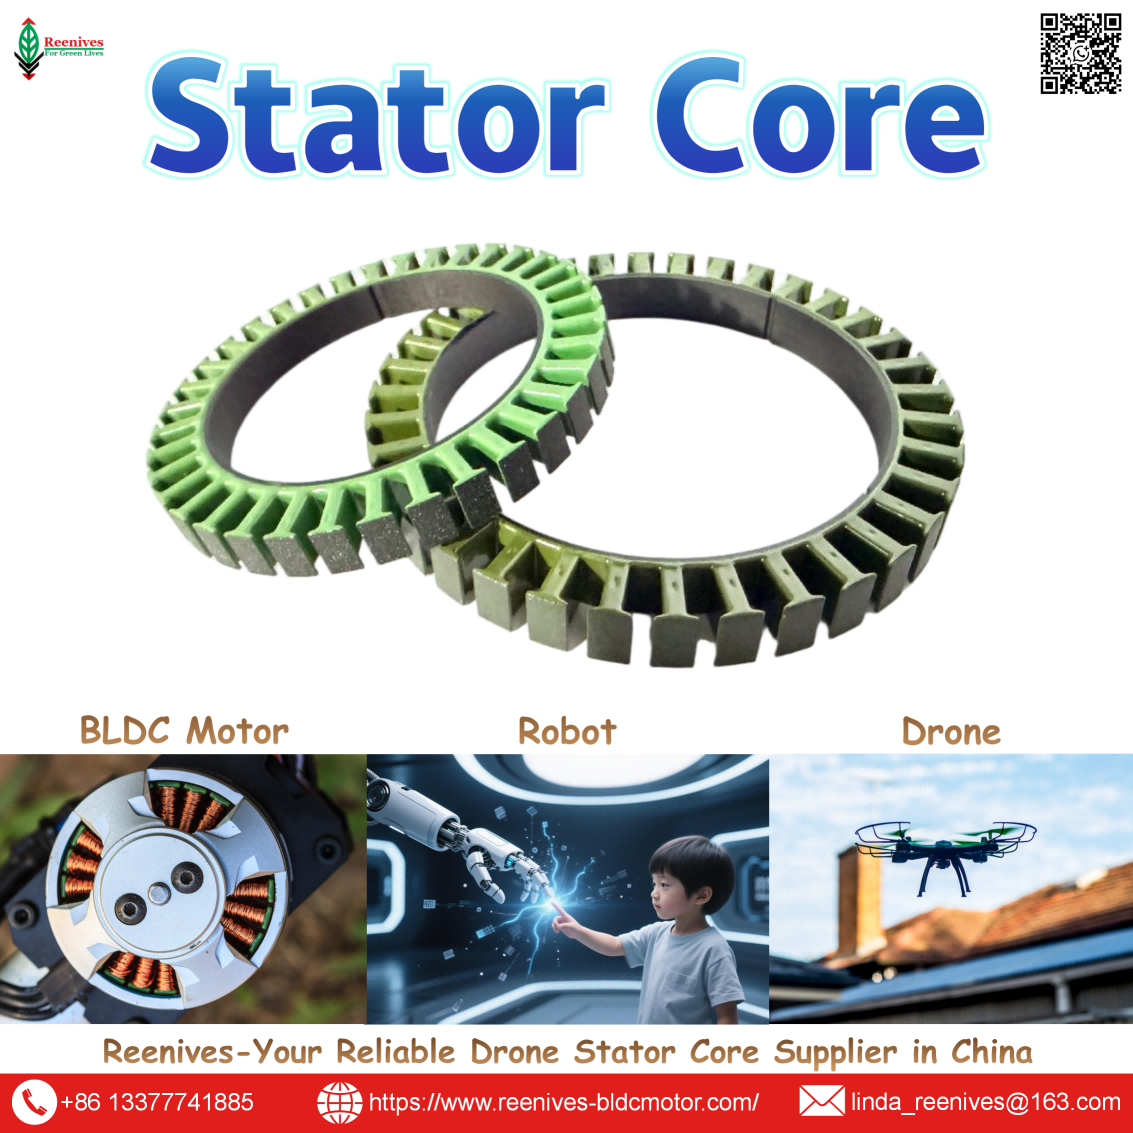
Drone Motor Winding Stator Parameters Explanation

Drone Motor Winding Stator Parameters Explained: What Each Number Controls, How It Is Measured, and Why It Matters
Most winding stator disputes between buyer and supplier come down to a single missing word: “measured.” A quote says “0.20 mm silicon steel” and the buyer assumes it means ≤8.5 W/kg; the supplier means the generic grade family range of 10–14 W/kg, and both are technically compliant with a phrase that neither side defined. A datasheet says “concentricity 0.02 mm” without stating whether that is measured on a bare stator or on an assembled stator-rotor pair. A purchase order lists “surge tested” without stating 100% coverage or a sample rate. Every one of these gaps produces a quote that looks comparable and is not.
The published parameter set resolves the ambiguity by attaching a number, a test standard, and a motor-level effect to each item. Reenives publishes its drone winding stator at 0.20 mm silicon steel, core loss ≤8.5 W/kg at 1.0 T / 400 Hz per IEC 60404-2, stacking factor ≥97.5% by the weight/dimension method, burr height <0.03 mm by optical comparator, critical tolerance ±0.05 mm, and uniform epoxy coating. The winding side adds ±0.05 N tension, ±0.03 mm placement accuracy, 75% slot fill in advanced processes, and 100% coverage of Hi-Pot, three-phase resistance, and surge waveform testing. Each of those values answers a different question, and a specification that omits any one of them leaves a failure mode unaddressed.
This guide explains every winding stator parameter in the order a procurement engineer should audit them: the core parameters that prevent damage, the winding parameters that determine whether the core’s potential survives, and the finished-part tests that detect what the process could not prevent. It is written for the engineer who has to write the RFQ and defend the selection decision, not for the buyer who just needs a price.
In this guide — jump to the section your project needs:
- What Is a Winding Stator, and Why Do Its Parameters Divide Into Three Layers?
- Winding Stator Configurations and the Parameters Each One Changes
- Parameter-by-Parameter Explanation: Core Loss, Stacking Factor, Burr, Concentricity, Coating, Tension, Slot Fill, and Test
- Application Profiles: Which Parameter Binds Which Drone, UAV, and FPV Mission
- A 5-Step Parameter Audit for Procurement Engineers
- FAQ: Core Loss, Stacking Factor, Burr, Concentricity, Tension, Slot Fill, and Surge Testing
- Summary: Specify the Number, the Standard, and the Location
What Is a Winding Stator, and Why Do Its Parameters Divide Into Three Layers?
A winding stator is a stator core that has received its copper windings. The bare core is a stack of individually insulated electrical steel laminations; the winding stator is that core after enameled copper wire has been inserted into its slots, arranged in a defined pattern, and terminated. The parameters that define it fall into three layers because each layer addresses a different failure mode, and each is measured at a different point in the manufacturing sequence.
| Layer | Parameters | Failure Mode It Addresses | Where It Is Measured |
|---|---|---|---|
| Core | Core loss; lamination thickness; stacking factor; burr height; critical tolerance; coating; slot-pole geometry | Iron heat; wasted flux density; interlaminar short; bore eccentricity; winding tool entry; insulation breakdown | On the finished core, before winding |
| Winding | Tension window; wire placement accuracy; wire diameter; turns; slot fill; winding pattern | Enamel micro-damage; loose coil; resistance imbalance; low copper density; wrong Kv | During winding, recorded per station or per batch |
| Test | Hi-Pot; 3-phase resistance; surge waveform; insulation resistance; phase balance | Latent turn-to-turn short; gross insulation failure; winding asymmetry | On 100% of finished winding stators |
Sources: Reenives drone winding stator core specification (core layer); published winding process parameters (winding layer); JYSTATOR drone stator winding specification (test layer: 100% Hi-Pot, 3-phase resistance, surge waveform).
The three layers are not interchangeable. A core that passes every core parameter can still be destroyed by a winding process that over-tensions the enamel. A winding that passes every process parameter can still hide a turn-to-turn short that only the surge test will reveal. A specification that names only one layer leaves the other two failure modes to the buyer — and those failure modes typically appear in the field, not on the bench.
Winding Stator Configurations and the Parameters Each One Changes
Before explaining the individual parameters, it is worth noting which ones move when the slot-pole configuration changes. The configuration sets the winding factor, the cogging profile, and the physical constraints the winding process must satisfy.
| Configuration | Slots | Poles | Parameters Most Affected | Typical Drone Fit |
|---|---|---|---|---|
| 12N14P | 12 | 14 | Winding factor ≈ 0.933; very low cogging; q ≈ 0.286; concentrated winding; short end turns | FPV, multirotor, and general UAV propulsion — the drone default |
| 9N12P | 9 | 12 | Different cogging signature; lighter stator; higher speed bias | Small outrunners and lightweight FPV builds |
| 18N24P | 18 | 24 | Higher slot count; different torque ripple profile; larger winding area | Larger outrunners and industrial UAV platforms |
| 24N28P | 24 | 28 | High slot count; smooth torque character; longer winding cycle | Heavy-lift, eVTOL, and high-torque propulsion |
Sources: Published 12N14P winding analysis (q ≈ 0.286; winding factor ≈ 0.933); Reenives slot/pole configuration record (9N12P, 12N14P, 18N24P, 24N28P).
For a 12N14P machine, slots per pole per phase calculate to q = 12 ÷ (14 × 3) ≈ 0.286, making it a fractional-slot concentrated winding. Each coil wraps primarily around a single tooth, shortening the end winding and reducing the inactive copper that adds weight and resistance without contributing to electromagnetic conversion. The slight slot-pole asymmetry means the magnets never align with all teeth simultaneously, which is why 12N14P delivers very low cogging torque. Those characteristics are not separate parameters — they are the consequences of the slot-pole coordinate, and they set the baseline against which every other parameter is measured.
Parameter-by-Parameter Explanation: Core Loss, Stacking Factor, Burr, Concentricity, Coating, Tension, Slot Fill, and Test
1. Core loss — ≤8.5 W/kg at 1.0 T / 400 Hz
What it is: the electrical power dissipated as heat in the lamination stack as the magnetic field cycles. It has two components. Hysteresis loss is proportional to frequency and the material’s coercivity. Eddy-current loss is proportional to the square of both lamination thickness and frequency.
How it is measured: IEC 60404-2 defines the Epstein-frame method, which requires a sinusoidal polarization waveform, a measurement temperature of 23°C ±5°C, and no external stress on the specimen.
Why the test point matters: a core-loss figure without its flux density and frequency is meaningless. Reenives specifies ≤8.5 W/kg at 1.0 T / 400 Hz. A 0.35 mm grade at the same test point runs roughly 28–35 W/kg, and a generic 0.20 mm grade family runs 10–14 W/kg. The published ≤8.5 W/kg is therefore a specific grade-and-process result, not a generic thickness claim.
Motor-level effect: at drone electrical frequencies (hundreds of Hz to over 1 kHz), iron loss is a direct tax on flight time and thermal margin. Lower core loss means a cooler stator, a higher continuous torque ceiling before derating, and a longer hover endurance.
2. Lamination thickness — 0.20 mm silicon steel
What it is: the thickness of each individual electrical steel sheet in the stack.
Why it is separate from core loss: thickness determines the eddy-current loss scaling (proportional to t²), but two 0.20 mm sheets from different grades can differ in hysteresis loss because of their silicon content and processing. Thickness and grade are specified together.
Motor-level effect: a 0.20 mm lamination is the drone baseline because the electrical frequency is high enough that thicker laminations generate significant eddy-current heat. Reenives specifies 0.20 mm silicon steel with a critical tolerance of ±0.05 mm.
3. Stacking factor — ≥97.5%
What it is: the ratio of actual magnetic steel volume to the total stack envelope volume, measured by the weight/dimension method. It quantifies how much non-magnetic gap (air and coating) sits between the active steel layers.
Why it is a separate audit line: a loose stack wastes the flux density the steel grade was selected to provide. Moving from a 96% to a 98% stacking factor increases effective magnetic flux density by roughly 6% without any change to the mill certificate. Reenives publishes ≥97.5%.
Motor-level effect: stacking factor is the difference between “the steel could theoretically do this” and “the finished stator actually does this.”
4. Burr height — <0.03 mm
What it is: the raised metal edge left on a lamination after stamping.
Why 0.03 mm is the limit: when laminations are stacked, burrs can pierce the interlamination insulation coating of the adjacent sheet, creating a local conductive path. That path produces interlaminar eddy currents, a hot spot, and eventually coating breakdown. A 0.20 mm lamination with a 0.03 mm burr has a 15% edge protrusion relative to its own thickness — exactly the scale at which coating penetration becomes likely during stacking and winding tension.
How it is measured: optical comparator edge scan. Reenives specifies <0.03 mm.
Motor-level effect: burr control is the difference between a stator that survives a season of thermal cycling and one that develops a latent hot spot in month three.
5. Critical tolerance and concentricity — ±0.05 mm and ≤0.02 mm
What they are: critical tolerance is the dimensional band on the stator bore, outer diameter, and stack height. Concentricity is the deviation of the stator bore centre from the outer diameter centre.
Why they matter together: the air gap is the difference between the stator bore radius and the rotor outer diameter radius. A 0.02 mm concentricity error on each side can produce a gap variation that is a meaningful fraction of a 0.10–0.12 mm FPV air gap.
How they are measured: metrology and vision measurement on the finished core. Reenives specifies critical tolerance ±0.05 mm and concentricity ≤0.02 mm for drone-grade cores.
Motor-level effect: a non-uniform air gap produces uneven magnetic pull, vibration, bearing load, and eventually eccentricity-driven bearing failure.
6. Coating — uniform epoxy
What it is: the interlamination insulation layer applied to each lamination to prevent adjacent sheets from shorting to each other.
Why it is not cosmetic: during winding, tension and tool contact can abrade or pierce the coating; during operation, thermal cycling and vibration stress it further. A uniform, pinhole-free layer survives both. A thin or voided layer produces a winding stator that passes the initial electrical test and fails after hours of flight as the insulation degrades.
How it is verified: visual and dielectric check. Reenives specifies uniform epoxy coating on its drone stator cores.
Motor-level effect: coating integrity is the barrier that keeps the interlaminar insulation intact across the service life of the motor.
7. Tension window — ±0.05 N / ±5 g
What it is: the allowable fluctuation in wire tension during the winding process.
Why the window is narrow: the wire is thin (0.18–0.25 mm single strand or 3×0.12–4×0.13 mm parallel), and the enamel coating is a few micrometres thick. Excessive tension stretches and thins the enamel; insufficient tension leaves a loose coil.
How it is measured: precision tension controller at ±5 g, or a closed-loop electronic tensioner with a dancer arm and load cell. Published winding process data places fluctuation within ±0.05 N.
Motor-level effect: tension control is the difference between a winding stator that passes surge testing and one that fails it after a month of flight.
8. Wire placement accuracy — ±0.03 mm
What it is: the positional accuracy of each wire turn within the slot.
Why it matters: uneven placement produces magnetic circuit asymmetry, uneven resistance across phases, and vibration. It also reduces the achievable slot fill because wire crossovers waste space.
How it is measured: servo-controlled wire guide with position feedback. Published data places accuracy better than ±0.03 mm.
Motor-level effect: placement accuracy is the difference between a motor that runs smooth and one that has a vibration signature the flight controller cannot tune out.
9. Slot fill factor — 30–40% manual vs 75% advanced
What it is: the ratio of copper cross-sectional area to total available slot area.
Why the range is so wide: traditional manual or low-tier machine winding yields roughly 30–40% because of unorganized wire crossovers and air gaps. Advanced multi-axis CNC with layered or interleaved patterns reaches 75%, with one supplier reporting 80% using electronic cam non-linear linkage control.
What limits it: the stator core’s slot opening geometry. Typically the winding space must leave at least three times the wire diameter for the needle or flyer to enter. A small slot opening designed to reduce cogging limits the achievable fill — a coupled design decision, not a winding-machine setting.
Motor-level effect: higher fill factor increases the torque constant (Kt) and reduces line-to-line resistance (R) without altering the motor’s physical footprint.
10. Wire diameter and turns — 0.18–0.25 mm and ≈12 turns/phase for KV900
What they are: the enameled copper wire gauge and the number of turns per phase.
How they relate to Kv: turns set Kv; wire gauge sets current capacity. A 12N14P drone stator at KV900 typically uses approximately 12 turns per phase (4 turns per slot × 3 slots per phase) on 0.18–0.25 mm wire. Changing the connection from wye to delta multiplies Kv by √3 for the same winding.
Motor-level effect: a turn count calculated for one connection and executed on the other will miss the KV target by roughly 73% while passing every electrical test.
11. Winding pattern — ABCABCABCABC for 12N14P
What it is: the sequence of phase coils around the stator and the direction of each coil.
Why it matters: a single reversed tooth creates a phase imbalance the ESC interprets as a desync condition. The motor will spin but will not run cleanly. Published 12N14P patterns include ABCABCABCABC, with direction documented tooth by tooth.
How it is verified: back-EMF waveform comparison across the three phases.
Motor-level effect: pattern accuracy is the difference between a motor that runs at its design Kv and one that runs at design Kv with elevated cogging and heat.
12. Electrical test coverage — 100% Hi-Pot, 3-phase resistance, surge waveform
What they are: the three tests that verify the finished winding stator. Hi-Pot tests insulation integrity. Three-phase resistance tests winding consistency (four-wire measurement, ±0.5% tolerance). Surge waveform testing detects turn-to-turn short circuits.
Why surge testing is the differentiator: a turn-to-turn short can leave phase resistance within tolerance while generating a hot spot under load. A resistance check alone passes the defect; the surge waveform test does not.
Coverage: published drone stator specifications call for 100% coverage of all three tests on every wound stator.
Motor-level effect: surge testing is the last gate between a latent short and a field failure.
| Parameter | Published Value | Test Standard / Method | Motor-Level Effect |
|---|---|---|---|
| Core loss | ≤8.5 W/kg @ 1.0 T / 400 Hz | IEC 60404-2 Epstein frame | Iron heat and continuous torque ceiling |
| Lamination thickness | 0.20 mm silicon steel | Micrometer, batch sampling | Eddy-current loss scaling |
| Stacking factor | ≥97.5% | Weight / dimension | Effective flux density of the finished stack |
| Burr height | <0.03 mm | Optical comparator edge scan | Prevents coating piercing and interlaminar short |
| Critical tolerance | ±0.05 mm | Vision / metrology | Consistent seating and air-gap geometry |
| Concentricity | ≤0.02 mm | Vision measurement on finished core | Air-gap uniformity and vibration |
| Coating | Uniform epoxy | Visual + dielectric check | Interlaminar insulation across service life |
| Tension window | ±0.05 N / ±5 g | Precision controller or closed-loop tensioner | Enamel integrity and short risk |
| Placement accuracy | ±0.03 mm | Servo-controlled wire guide | Phase balance and vibration |
| Slot fill | 30–40% vs 75% | Copper area / slot area | Kt up and R down without footprint change |
| Test coverage | 100% Hi-Pot, 3φ R, surge | Dedicated test station | Latent short detection |
Sources: Reenives drone winding stator core specification; IEC 60404-2; published winding process data (±0.05 N, ±0.03 mm, 30–40% vs 75%); JYSTATOR 100% electrical test specification.
The description-versus-specification trap: a parameter without a test standard and a measurement location is a description, not a specification. “Core loss ≤8.5 W/kg” is a description. “Core loss ≤8.5 W/kg at 1.0 T / 400 Hz, measured per IEC 60404-2 on the finished stack” is a specification. The same applies to concentricity (“≤0.02 mm, measured on the assembled stator-rotor pair”), slot fill (“achieved with the production wire, reported per sample”), and surge testing (“100% coverage, records bound to batch”). A quote that omits the standard and the location leaves the interpretation to the supplier.
Application Profiles: Which Parameter Binds Which Drone, UAV, and FPV Mission
| Mission Class | Binding Parameter | Why | Specification to Write |
|---|---|---|---|
| FPV racing / high-RPM | Core loss at high frequency + surge test coverage | Electrical frequency amplifies iron heat; latent short fails under thermal load | ≤8.5 W/kg @ 1.0 T / 400 Hz; 100% surge waveform test |
| Cinematic / inspection FPV | Concentricity + phase resistance balance | Vibration reaches the camera before it reaches the motor | ≤0.02 mm concentricity; 3-phase resistance within tolerance |
| Agricultural spraying UAV | Coating integrity + slot fill | Long, wet, current-heavy duty cycle stresses insulation and copper density | Uniform epoxy coating; fill matched to slot opening; 100% Hi-Pot |
| Heavy-lift / logistics UAV | Stacking factor + core loss | Continuous torque depends on flux density and low iron heat | ≥97.5% stacking factor; published core loss on finished stack |
| eVTOL / high-torque propulsion | Stacking factor + critical tolerance at scale | Large-diameter stators amplify dimensional effects | ≥97.5% stacking; ±0.05 mm tolerance verified on full bore |
The pattern is that the binding parameter tracks the mission’s dominant failure mechanism. FPV racing binds on core loss and surge coverage because high electrical frequency amplifies iron heat and the consequences of a latent short are severe. Cinematic and inspection platforms bind on concentricity and phase balance because vibration reaches the payload first. Agricultural platforms bind on coating and slot fill because the duty cycle is long, wet, and current-heavy. Heavy-lift and eVTOL bind on stacking factor and dimensional tolerance at scale, because continuous torque and large diameters expose both.
A 5-Step Parameter Audit for Procurement Engineers
- Audit the core parameters first, and require the standard and measurement location for each. Write “core loss ≤8.5 W/kg at 1.0 T / 400 Hz, measured per IEC 60404-2 on the finished stack,” “stacking factor ≥97.5% by the weight/dimension method,” “burr height <0.03 mm by optical comparator,” “critical tolerance ±0.05 mm,” and “concentricity ≤0.02 mm measured on the finished core.” A quote that restates all five is answering the core specification; one that names only “0.20 mm steel” is not.
- Audit the winding parameters against the core’s slot geometry. Confirm the wire diameter range (0.18–0.25 mm single or 3×0.12–4×0.13 mm parallel for 12N14P), the tension window (±0.05 N / ±5 g), the placement accuracy (±0.03 mm), and the slot fill target achieved on a sample with the production wire. The fill ceiling is set by the slot opening: roughly three times the wire diameter of entry clearance is required.
- Confirm the connection type and turn count are matched. A turn count calculated for wye will miss the KV target by roughly 73% if executed in delta (Kv,Δ = Kv,Y × √3). This is a parameter interaction that passes every electrical test because the winding itself is intact — it simply produces the wrong Kv.
- Require 100% coverage of Hi-Pot, 3-phase resistance, and surge waveform testing. Ask for a recent record showing a unit that failed surge testing and was rejected. A supplier with no rejected units is either perfect or not testing. Confirm the test data is bound to a batch or serial number so a field failure can be traced to a winding run.
- Run a trial wind with production stators and production wire. Send two to three stator cores and the exact wire specification, have them wind the sample, and inspect wire lay, slot fill, enamel condition at the slot edges, and the electrical test results before committing to volume. This is the only step that reveals whether the parameters in the quotation describe a process that actually works on your stator.
FAQ: Core Loss, Stacking Factor, Burr, Concentricity, Tension, Slot Fill, and Surge Testing
What does core loss mean on a drone motor winding stator, and at what test point is it specified?
Core loss is the power dissipated as heat in the stator lamination stack as the magnetic field cycles. It has two components: hysteresis loss, proportional to frequency and the material’s coercivity, and eddy-current loss, proportional to the square of both lamination thickness and frequency. It is specified at a defined polarization and frequency — commonly 1.0 T at 400 Hz for drone grades — and measured per IEC 60404-2 using the Epstein frame, which requires a sinusoidal polarization waveform, a measurement temperature of 23°C ±5°C, and no external stress on the specimen. Reenives publishes its 0.20 mm drone winding stator at ≤8.5 W/kg at 1.0 T / 400 Hz. A 0.35 mm grade at the same test point runs roughly 28–35 W/kg, which is why lamination thickness is a separate parameter.
Source: Reenives drone winding stator core specification (≤8.5 W/kg @ 1.0 T / 400 Hz); IEC 60404-2 Epstein-frame method; published 0.35 mm range (28–35 W/kg).
What is stacking factor, and why does it matter if the steel grade is already correct?
Stacking factor is the ratio of the actual magnetic steel volume to the total stack envelope volume, measured by the weight/dimension method. It quantifies how tightly the laminations are packed and therefore how much non-magnetic gap (air and insulation coating) sits between the active steel layers. Reenives publishes a stacking factor of ≥97.5% for its drone winding stator cores. A loose stack wastes the flux density the steel grade was selected to provide: moving from a 96% to a 98% stacking factor increases effective magnetic flux density by roughly 6% without any change to the mill certificate. This is why stacking factor is a separate audit line, not an assumption inherited from the material.
Source: Reenives drone winding stator core specification (≥97.5% stacking factor); stacking factor performance analysis (6% flux density gain from 96% to 98%).
What does burr height control, and why is a 0.03 mm limit significant?
Burr height is the raised metal edge left on a lamination after stamping. When laminations are stacked, burrs can pierce the interlamination insulation coating of the adjacent sheet, creating a local conductive path between layers. That path produces interlaminar eddy currents, a hot spot, and eventually coating breakdown. Reenives specifies burr height <0.03 mm on its drone winding stator cores, measured by optical comparator edge scan. The limit is significant because a 0.20 mm lamination with a 0.03 mm burr has a 15% edge protrusion relative to its own thickness — which is exactly the scale at which coating penetration becomes likely during stacking and winding tension.
Source: Reenives drone winding stator core specification (<0.03 mm burr); published interlaminar short mechanism analysis.
What does concentricity ≤0.02 mm mean on a winding stator, and how is it verified?
Concentricity is the deviation of the stator bore centre from the stator outer diameter centre — effectively how far off-centre the bore sits. Reenives specifies ≤0.02 mm for drone-grade winding stators, verified by vision measurement on the finished core. It matters because the air gap is the difference between the stator bore radius and the rotor outer diameter radius. A 0.02 mm concentricity error on each side can produce a gap variation that is a meaningful fraction of a 0.10–0.12 mm FPV air gap, and a non-uniform gap produces uneven magnetic pull, vibration, bearing load, and ultimately eccentricity-driven bearing failure. Concentricity belongs to the pair, not to the stator alone, which is why matched stator-rotor supply is the reliable way to control it.
Source: Reenives drone-grade stator concentricity specification; published FPV air-gap range (0.10–0.12 mm); eccentricity-to-bearing-failure analysis.
What tension window should a winding stator be wound within, and why ±0.05 N?
Published winding process data places tension fluctuation within ±0.05 N and wire placement accuracy better than ±0.03 mm. The window is narrow because the wire is thin — 0.18–0.25 mm single strand or 3×0.12–4×0.13 mm parallel for a 12N14P drone stator — and the enamel coating is a few micrometres thick. Excessive tension stretches and thins the enamel, creating a turn-to-turn short risk that may not appear until the motor fails after hours of flight. Insufficient tension leaves a loose coil that reduces slot fill and vibrates under flight loads. A precision tension controller at ±5 g, or a closed-loop electronic tensioner with a dancer arm and load cell, is the equipment-level answer to the ±0.05 N requirement.
Source: Published winding process data (±0.05 N fluctuation; ±0.03 mm placement; 0.18–0.25 mm wire; ±5 g controller).
What slot fill factor should a drone winding stator achieve, and what limits it?
Slot fill factor is the ratio of copper cross-sectional area to the total available slot area. Traditional manual or low-tier machine winding yields roughly 30–40%; advanced multi-axis CNC winding with layered or interleaved patterns reaches 75%, with one supplier reporting 80% using electronic cam non-linear linkage control. Higher fill factor increases the torque constant (Kt) and reduces line-to-line resistance (R) without altering the motor’s physical footprint. The ceiling is set by the stator core’s slot opening geometry: typically the winding space must leave at least three times the wire diameter for the needle or flyer to enter, so a small slot opening designed to reduce cogging limits the achievable fill. Slot geometry and winding process are a coupled decision.
Source: Published drone winding selection guide (30–40% manual; CNC layered patterns); Nuoyuan winding analysis (75–80%; three-times wire diameter entry clearance).
Why is 100% surge waveform testing more important than a resistance check on a winding stator?
A resistance check measures the total DC resistance of a phase and compares it to a target. A turn-to-turn short inside a coil can leave the total phase resistance within tolerance because only a small number of turns are shorted together, while the short itself creates a local hot spot under load. The surge waveform test applies a fast voltage pulse to the winding and compares the resulting waveform to a reference; a turn-to-turn insulation defect distorts the waveform in a way that resistance cannot reveal. Published drone stator specifications call for 100% coverage of Hi-Pot, three-phase resistance, and surge waveform testing on every wound stator, with four-wire resistance measurement to ±0.5% accuracy.
Source: JYSTATOR drone stator winding specification (100% Hi-Pot, 3-phase resistance, surge waveform); published stator test framework; four-wire measurement to ±0.5%.
Summary: Specify the Number, the Standard, and the Location
Every drone motor winding stator parameter is only meaningful when it is paired with a test standard and a measurement location. “0.20 mm silicon steel” is a material category; “core loss ≤8.5 W/kg at 1.0 T / 400 Hz, measured per IEC 60404-2 on the finished stack” is a specification. “Concentricity 0.02 mm” is a number; “concentricity ≤0.02 mm measured on the finished core” is a process requirement. The same distinction applies to every other parameter in the set.
The published parameter set for a drone-grade winding stator is concrete: 0.20 mm silicon steel, core loss ≤8.5 W/kg at 1.0 T / 400 Hz, stacking factor ≥97.5%, burr height <0.03 mm, critical tolerance ±0.05 mm, concentricity ≤0.02 mm, and uniform epoxy coating on the core side; ±0.05 N tension, ±0.03 mm placement accuracy, 0.18–0.25 mm wire, ≈12 turns per phase for KV900, 75% slot fill in advanced processes, and ABCABCABCABC winding on the winding side; and 100% coverage of Hi-Pot, three-phase resistance, and surge waveform testing on the finished-part side.
The procurement takeaway is that a winding stator quote should be audited parameter by parameter, with the standard and the location attached to each one. A supplier who can restate all three layers, show finished-stack data, and produce a rejected unit from their inspection process is describing a winding stator. A supplier who can only quote a wire gauge and a turn count is describing a coil — and leaving the three failure modes those layers address to the buyer.
Need winding stator cores with auditable parameters?
Reenives manufactures precision stamped stator cores for drone winding: 0.20 mm silicon steel, core loss ≤8.5 W/kg at 1.0 T / 400 Hz per IEC 60404-2, stacking factor ≥97.5%, burr height <0.03 mm, critical tolerance ±0.05 mm, concentricity ≤0.02 mm, and uniform epoxy coating, in 9N12P, 12N14P, 18N24P, and 24N28P slot/pole configurations. Matched stator-rotor pairs, private mould development, and free samples are available for qualified engineering evaluations.
WhatsApp: +86-13377741885
Email: linda_reenives@163.com
Official website: www.reenives-bldcmotor.com
Dongguan Runlu Motor Technology Co., Ltd.
Reenives — Drone Motor One-Stop Solution Supplier
Reenives is a professional drone stator core manufacturer, founded in 2022. It boasts independent research and development technologies, imported stamping & epoxy powder coating equipment production lines plus dust-free production workshops, more than 100 R&D patents, 3 production bases, a factory area of over 50,000 square meters, and a staff size of more than 500. From production to sales, we support bulk purchasing, private mould development, and sample making, and can provide tailor-made perfect solutions for your production and usage scenarios. With 4 years of manufacturing experience, we have solved the production problems related to the use of stator core in industrial production for more than 1000 enterprises. We can ship globally (with complete export qualifications). Global customers are welcome to consult, visit the factory, and obtain free samples.
0.20 mm silicon steelCore loss ≤8.5 W/kg @ 1.0 T / 400 HzStacking factor ≥97.5%Burr <0.03 mmConcentricity ≤0.02 mmUniform epoxy coating9N12P · 12N14P · 18N24P · 24N28PGlobal export qualifications
Reenives: Global Leading BLDC Drone Motor Stator Winding Service Supplier
Reenives: Global Leading Fully Automatic Stator Winding Machines Supplier
Related Article