Reenives: Global Leading Fully Automatic Stator Winding Machines Supplier

Fully Automatic Stator Winding Machines for Drone Motors: Tension, Slot Fill, Multi-Station Throughput, and the Stator Core They Must Match
The most expensive fully automatic stator winding machine is the one that cannot hold ±0.05 N tension on 0.18 mm wire, or that lands at 35% slot fill when the motor design assumed 75%. Drone BLDC stators are small, the wire is thin, and the turns count is high — a 12N14P drone stator at KV900 typically runs 12 turns per phase on 0.18–0.25 mm wire. The winding window is narrow, and a machine that is “fully automatic” in its motion sequence but imprecise in its tension and placement control will produce stators that pass a visual check and fail in the field. The failure mode is not a broken wire; it is a micro-damaged enamel that shorts after hours of thermal cycling.
The published parameters show what a production-grade machine must hold. Fully automatic winding requirements place tension fluctuation within ±3%, with high-end equipment achieving ±0.05 N. Wire placement accuracy is controlled within ±0.02 mm, with repeat positioning accuracy of ±0.05 mm or better. Flyer winding, the standard architecture for drone outrunners, operates at 2,000–5,000 rpm, placing high demands on spindle dynamic balancing and servo responsiveness. Manual or low-tier winding yields a slot fill factor of roughly 30% to 40%; advanced multi-axis CNC with layered patterns pushes substantially higher, with published reports of 75% and even 80%. And the stator core underneath all of it sets the physical boundary: Reenives publishes drone stator cores with 0.20 mm silicon steel, core loss ≤8.5 W/kg at 1.0 T / 400 Hz, stacking factor ≥97.5%, and burr height <0.03 mm.
This guide is written for the process engineer or procurement lead specifying a fully automatic stator winding machine for drone motor production. It separates the machine architectures by stator geometry, presents the published tension, placement, slot fill, speed, and throughput parameters with their sources, maps the machine configuration to drone mission profiles, and closes with a five-step selection workflow that includes the stator core audit the machine alone cannot perform.
In this guide — jump to the section your project needs:
- What Is a Fully Automatic Stator Winding Machine? Automation, Precision, and the Matching Problem
- Machine Configurations: Flyer vs Needle, Single vs Multi-Station, Semi vs Fully Automatic
- Published Parameters: Tension, Placement Accuracy, Slot Fill, Speed, Station Count, and Stator Core Constraints
- Application Profiles: Which Machine Configuration Binds Which Drone Mission
- A 5-Step Fully Automatic Winding Machine Selection Workflow
- FAQ: Automation, Tension, Slot Fill, Flyer vs Needle, Multi-Station, and Stator Compatibility
- Summary: Automate the Process, Not Just the Motion
What Is a Fully Automatic Stator Winding Machine? Automation, Precision, and the Matching Problem
A fully automatic stator winding machine performs the complete winding cycle without operator intervention: it loads the stator, winds the coils in the programmed pattern, indexes between slots, arranges the wire, cuts it, and unloads the finished stator. Published drone-specific flyer machines add PLC and servo control with recipe storage for 30 parameter sets, and optional automatic feeding, winding, indexing, wire arrangement, cutting, and unloading. But the automation label is the least informative part of the specification.
What matters for a drone motor programme is whether the machine can hold the process parameters that determine motor performance and field reliability. Three parameters define that capability, and a machine that fails on any one of them will not produce a reliable stator regardless of how automatic its motion sequence is.
| Matching Dimension | What It Determines | Published Fully Automatic Reference | Failure If Mismatched |
|---|---|---|---|
| Tension control | Whether the enamel survives the winding process | Within ±3%; high-end at ±0.05 N; drone flyer at ±5 g | Turn-to-turn short risk from enamel micro-damage; loose coils that vibrate |
| Wire placement accuracy | Coil geometry, phase balance, slot fill consistency | Within ±0.02 mm; repeat positioning ±0.05 mm | Magnetic circuit asymmetry; uneven resistance across phases; vibration |
| Slot fill capability | Copper density, and therefore Kt and R | Manual/low-tier 30–40%; advanced CNC layered up to 75–80% | Motor underperforms its torque constant and overheats at designed current |
Sources: Vacuz fully automatic winding requirements (±3%, ±0.05 N; ±0.02 mm placement; ±0.05 mm repeat positioning); 3115 drone external winding machine specification (±5 g tension); Qiwei drone winding selection guide (30–40% manual vs CNC layered; 75–80% advanced).
The fourth dimension is not a machine parameter at all — it is the stator core the machine must wind. Slot opening geometry determines whether an automated needle or flyer can enter and how much effective slot area is available. Insulation coating integrity determines how much tension the enamel can survive. Burr height can pierce the coating during winding and create a latent short. Dimensional tolerance controls how consistently the stator seats in the fixture. A winding machine cannot compensate for a stator core that is out of tolerance or has a compromised coating, which is why the stator specification belongs in the same conversation as the machine quotation.
Machine Configurations: Flyer vs Needle, Single vs Multi-Station, Semi vs Fully Automatic
Flyer versus needle: the architecture decision
| Architecture | Winding Mechanism | Best Suited For | Drone Relevance |
|---|---|---|---|
| Flyer (external / outslot) | High-speed rotating fork orbits the stator; wire guided into outward-facing slots | Outrunner drone motors, heavy-lift agriculture drones, RC aircraft | Mainstream for 12N14P drone outrunners; published speeds of 2,000–5,000 rpm with high demand on spindle balancing |
| Needle (internal / inslot) | Precision nozzle reciprocates through narrow inward-facing slot openings | Pumps, power tools, internal-slot stators, some micro-drone profiles | Not the default for drone outrunners; requires carbide or ceramic-coated nozzle to protect enamel at high friction |
Sources: Qiwei drone winding selection guide (flyer for standard multirotor outrunners and heavy-lift agriculture; needle for internal profiles); Vacuz fully automatic requirements (flyer speeds 2,000–5,000 rpm; needle nozzle wear resistance).
The architecture decision is dictated by slot orientation. A flyer cannot wind a stator whose slots face inward, and a needle cannot reach an outward-facing slot efficiently. For drone outrunners, the stator sits inside and the slots face outward, so the flyer is the standard. Published drone-specific flyer machines run at 800–1,500 rpm for fine wire and 0.18–0.25 mm single-strand or 3×0.12–4×0.13 mm parallel winding, whereas the broader flyer architecture can reach 2,000–5,000 rpm for heavier wire. The practical constraint for drone wire is not maximum spindle speed but tension control and wire break detection at the fine-wire end.
Single versus multi-station: the throughput lever
| Configuration | Mechanism | Published Throughput Effect | Best Fit |
|---|---|---|---|
| Single-station | Spindle idles during loading and unloading | Baseline; no overlap between winding and handling | Prototyping, low-volume, multi-model development |
| Dual-station | Winding and part handling overlap on a rotary table | Effectively doubles production capacity; transition time reduced from ~1 s to 0.1 s with pre-activated tensioner at the idle station | Mid-volume production |
| Four-station | Full rotary table with multiple winding positions | 4-station recommended for mass production on published drone flyer machines | High-volume FPV and UAV motor production |
Sources: Vacuz multi-station analysis (single-station idle; dual/quad-station overlap; transition 1 s → 0.1 s); 3115 drone external winding machine specification (4 stations recommended for mass production).
The station count is a volume decision, not a precision decision. A dual-station machine with a ±0.05 N tension controller produces the same electrical quality as a four-station machine; it simply does so at lower throughput. The fully automatic value appears when the annual volume justifies the tooling and integration cost, and when the model mix is stable enough that changeover time does not erode the throughput advantage.
Published Parameters: Tension, Placement Accuracy, Slot Fill, Speed, Station Count, and Stator Core Constraints
Tension control: the parameter that decides enamel survival
Published fully automatic winding requirements place tension fluctuation within ±3%, with high-end equipment achieving ±0.05 N. Drone-specific flyer machines use a precision tension controller at ±5 g to prevent breakage of fine wires and over-stretching. Closed-loop systems monitor copper wire tension in real time and adjust dynamically to keep fluctuation within a small range, and advanced systems automatically fine-tune as the wire spool diameter decreases, eliminating manual intervention. The two failure modes are symmetric: excessive tension stretches and thins the enamel, creating a turn-to-turn short risk that may not appear until the motor fails after hours of flight; insufficient tension leaves a loose coil that reduces slot fill and vibrates under flight loads.
Wire placement accuracy: the parameter that decides phase balance
Published precision requirements control winding position accuracy within ±0.02 mm to avoid magnetic circuit asymmetry due to offset. Repeat positioning accuracy when winding multiple slots is controlled within ±0.05 mm to ensure consistency of electromagnetic performance across adjacent slots. The laser displacement sensor monitors copper wire position in real time, and once deviation exceeds the threshold, the system automatically adjusts the wire arrangement mechanism. For a drone motor, placement error manifests as uneven phase resistance, which becomes torque ripple and localized heating.
Slot fill factor: 30–40% manual versus 75–80% advanced
Traditional manual or low-tier machine winding yields a copper slot fill factor of roughly 30% to 40% due to unorganized wire crossovers and air gaps. Advanced drone winding machines use ultra-precise, multi-axis CNC positioning to execute layered or interleaved winding patterns, maximizing copper density. Published advanced processes report slot fill up to 75%, with one supplier raising fill from 75% to 80% using electronic cam non-linear linkage control. The motor-level consequence is direct: higher fill factor increases the torque constant (Kt) and reduces line-to-line resistance (R) without altering the motor’s physical footprint.
Speed and station count: the throughput parameters
Flyer winding for external stators typically operates at 2,000–5,000 rpm, placing high demands on spindle dynamic balancing and servo responsiveness. Drone-specific flyer machines for fine wire often run 800–1,500 rpm, with dual-station and four-station configurations; four stations are recommended for mass production. Published dual-station setups pre-activate the tensioner at the idle station while the other station finishes winding, reducing transition time from nearly 1 second to 0.1 seconds.
Stator core constraints: the published Reenives specification
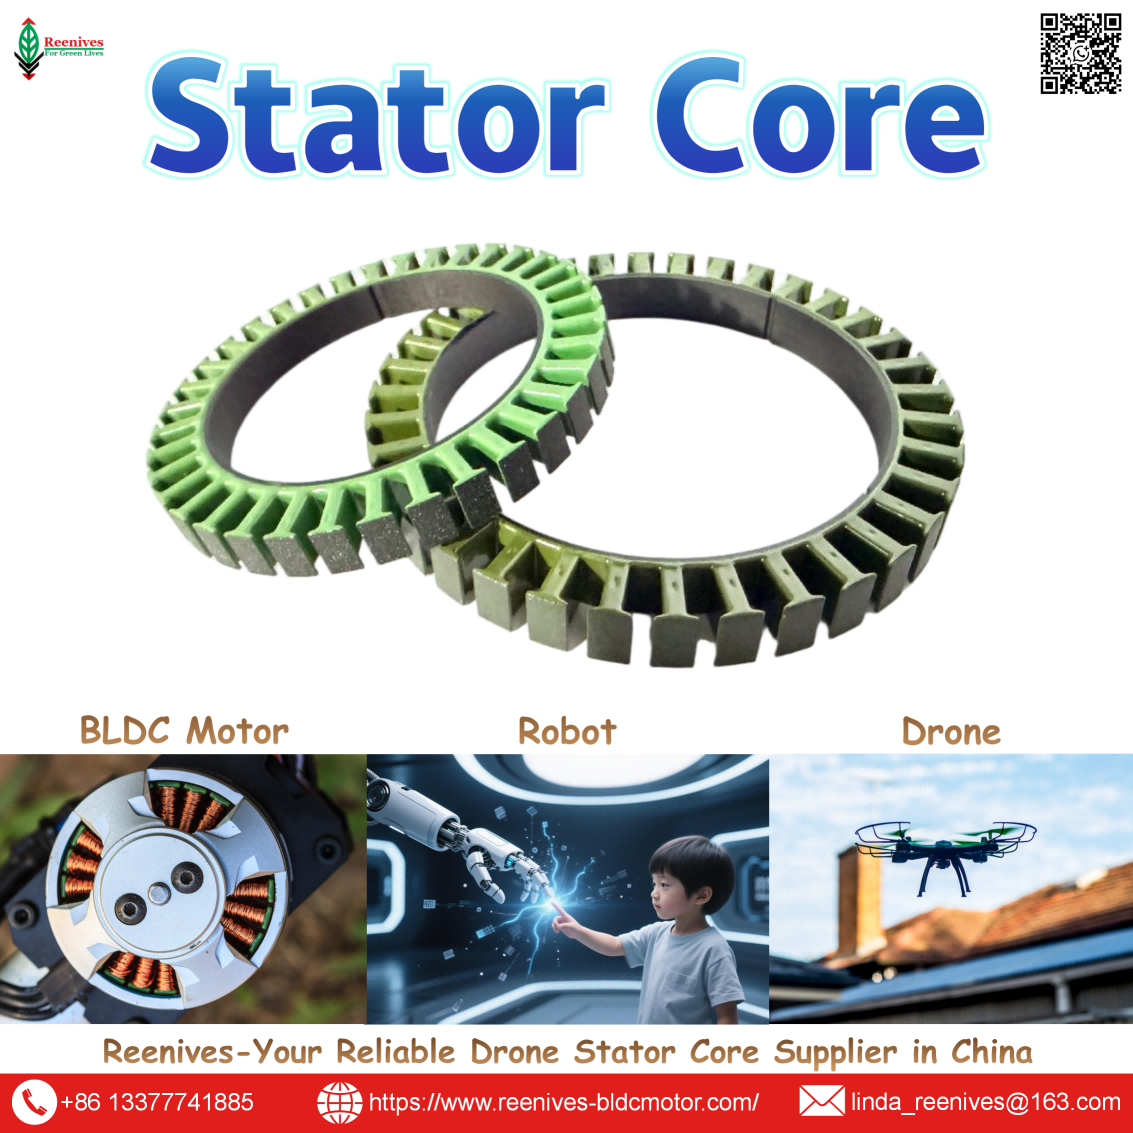
Reenives publishes drone stator cores with 0.20 mm silicon steel, core loss ≤8.5 W/kg at 1.0 T / 400 Hz, stacking factor ≥97.5%, burr height <0.03 mm, and epoxy coating. These are the parameters that set the physical boundary for the winding machine. Slot opening geometry determines tool entry; coating integrity determines how much tension the enamel can survive; burr height determines whether the coating is pierced during winding; dimensional tolerance determines how consistently the stator seats in the fixture.
The automation illusion: a machine that automates the motion sequence but holds tension at ±0.5 N instead of ±0.05 N is not a precision winding machine — it is a fast machine with a latent defect rate. The automation label describes the operator’s role, not the process capability. The procurement audit should ask for the tension fluctuation test report, the placement accuracy verification, and the slot fill achieved on a sample stator with the production wire, not the machine’s automation level.
Application Profiles: Which Machine Configuration Binds Which Drone Mission
| Mission Class | Stator / Wire Profile | Binding Machine Configuration | Why |
|---|---|---|---|
| FPV racing / high-RPM | Small 12N14P; 0.18–0.25 mm wire; high turns count | Flyer, dual-station, ±0.05 N tension, wire break detection | Fine wire at speed is prone to enamel micro-damage; a single break can wrap the stator and damage previously wound coils |
| Cinematic / inspection | 12N14P; moderate wire; emphasis on turn consistency | Flyer with programmable layered patterns and ±0.02 mm placement accuracy | Motor-to-motor resistance variation causes uneven thrust and vibration that reaches the camera |
| Agricultural / heavy-lift | Larger outrunner; thicker wire or parallel strands; high current | Flyer, four-station, multi-strand tension control | Higher current demands more copper; parallel strands require uniform tension across strands to avoid uneven resistance |
| Micro / whoop-class | Very small stator; 0.1 mm-class wire | Flyer with precision tension at the fine-wire limit | The tension window is narrowest at the smallest wire diameter; a standard tensioner may not resolve the required force accurately |
| Full motor production line | Multiple stator SKUs; volume production | Integrated winding module within a motor assembly line; MES traceability | The winder becomes one station in a chain that includes magnet insertion, balancing, and end-of-line testing; integration capability matters as much as standalone performance |
The pattern is that the binding machine configuration tracks the wire diameter and the current demand. FPV and micro platforms bind on tension resolution and wire break detection. Cinematic platforms bind on placement accuracy and phase balance. Agricultural and heavy-lift platforms bind on multi-strand capability and station count. A full production line binds on integration and traceability, because the winder’s output must be matched to the rotor and test stations downstream.
A 5-Step Fully Automatic Winding Machine Selection Workflow
- Determine the stator slot orientation before comparing machine architectures. Confirm whether the slots face outward (outrunner drone motor) or inward (internal-slot motor). Outward-facing slots point to a flyer winding machine; inward-facing slots require a needle machine. This is the first decision, and it eliminates roughly half the market before price comparison begins. Published drone outrunner guidance is consistent: flyer winding is the mainstream method for 12N14P outrunners.
- Define the wire diameter range and require the tension window, not just the automation feature. State the wire diameters and strand configurations the production plan requires — for example 0.18–0.25 mm single strand and 3×0.12–4×0.13 mm parallel for a 12N14P drone stator. Require tension fluctuation within ±3% at minimum, with high-end equipment at ±0.05 N or ±5 g. Ask for the tension fluctuation test report. A machine that quotes a tension range but not a resolution has not specified the parameter that prevents enamel damage.
- Set a slot fill target and ask how the machine achieves it. Published manual and low-tier winding lands at 30–40% fill. If the motor design assumes a higher fill, the machine must have multi-axis CNC positioning and programmable layered or interleaved patterns. Ask for the fill factor achieved on a sample stator with the production wire, not a theoretical maximum. The stator core’s slot opening geometry sets the ceiling, so this step connects directly to the next.
- Audit the stator core that the machine will wind. Require the stator core to be specified with a uniform, pinhole-free epoxy coating, controlled burr height, and critical-dimension tolerance at or better than ±0.05 mm. Reenives publishes drone stator cores with 0.20 mm silicon steel, core loss ≤8.5 W/kg at 1.0 T / 400 Hz, stacking factor ≥97.5%, and burr height <0.03 mm. A stator with burrs that pierce the coating during winding creates a latent short that no machine setting can detect.
- Send sample stators and wire for a trial wind before committing to the purchase. Published purchasing guidance for winding machines is explicit: send 2–3 stator samples and the wire specification to the supplier and have them run a trial wind, then inspect wire lay, slot fill, and any signs of wire damage or skipping. Only after the sample passes should price and configuration be discussed. Then confirm the hidden-cost checklist — fixtures, auto-loading, MES integration, freight, installation, and commissioning — and calculate the total cost against the production plan.
FAQ: Automation, Tension, Slot Fill, Flyer vs Needle, Multi-Station, and Stator Compatibility
What makes a stator winding machine “fully automatic” for drone motor production?
A fully automatic stator winding machine performs the complete winding cycle without operator intervention: automatic stator loading, winding, wire arrangement, indexing between slots, wire cutting, and unloading. Published drone-specific flyer machines add PLC and servo control with recipe storage for 30 parameter sets, and optional automatic feeding, winding, indexing, wire arrangement, cutting, and unloading. The distinction that matters for procurement is not the automation label but the process parameters it can hold repeatably: tension fluctuation within ±3% with high-end equipment at ±0.05 N, wire placement accuracy within ±0.02 mm, and slot fill factor that manual or low-tier winding cannot reach.
Source: Vacuz fully automatic winding requirements (±3%, ±0.05 N; ±0.02 mm placement); 3115 drone external winding machine specification (PLC + servo, 30 recipe sets, automatic functions).
What tension control accuracy should a fully automatic drone stator winding machine hold?
Published fully automatic winding requirements place tension fluctuations within ±3%, with high-end equipment achieving a precision of ±0.05 N. Drone-specific flyer machines use a precision tension controller at ±5 g to prevent breakage of fine wires and over-stretching, and closed-loop systems monitor copper wire tension in real time to keep fluctuation within a small range. As the wire spool diameter decreases, tension tends to drift; advanced systems automatically fine-tune via a closed-loop monitor based on spindle current. Excessive tension damages the enamel and creates a turn-to-turn short risk; insufficient tension leaves a loose coil that reduces slot fill and vibrates in flight.
Source: Vacuz fully automatic winding requirements (±3%, ±0.05 N; closed-loop fine-tuning); 3115 drone external winding machine specification (±5 g precision tension).
What slot fill factor can a fully automatic winding machine achieve for drone stators?
Traditional manual or low-tier machine winding yields a copper slot fill factor of roughly 30% to 40% due to unorganized wire crossovers and air gaps. Advanced drone winding machines use ultra-precise, multi-axis CNC positioning to execute layered or interleaved winding patterns, maximizing copper density. Published advanced processes report slot fill factors up to 75%, with one supplier raising fill from 75% to 80% using electronic cam non-linear linkage control. The ceiling is set by the stator core’s slot opening geometry: typically the winding space must leave at least three times the wire diameter for the needle to enter, so slot geometry and winding process are a coupled design decision.
Source: Qiwei drone winding selection guide (30–40% manual; CNC layered patterns); Nuoyuan winding analysis (75–80%; three-times wire diameter entry clearance).
What is the difference between flyer and needle winding for fully automatic drone stator machines?
The architecture must match the stator’s slot orientation. Flyer winding uses a high-speed rotating fork that orbits the stator and guides wire into outward-facing slots — the standard for drone outrunner motors, running at 2,000–5,000 rpm with high demands on spindle dynamic balancing and servo responsiveness. Needle winding uses a precision nozzle that reciprocates through narrow inward-facing slot openings, suited to internal-winding stators such as pumps and power tools. For 12N14P drone outrunners, flyer winding is the mainstream production method. A needle machine cannot wind an outward-facing slot efficiently, and a flyer machine cannot reach an inward-facing slot at all.
Source: Qiwei drone winding selection guide (flyer vs needle by slot orientation); Vacuz fully automatic requirements (flyer speeds 2,000–5,000 rpm; needle nozzle requirements).
How do multi-station configurations improve fully automatic stator winding throughput?
In a single-station system, the spindle remains idle during loading and unloading. Dual-station or four-station rotary-table machines allow winding and part handling to occur simultaneously, effectively doubling production capacity. Published high-efficiency dual-station setups go further: as the final turns are wound at Station A, the tensioner at Station B is pre-activated to establish the required tension, reducing the transition time between stations from nearly 1 second to just 0.1 seconds. Four stations are recommended for mass production. The published 3115 drone motor external winding machine is available in dual-station and four-station configurations.
Source: Vacuz multi-station analysis (overlap; 1 s → 0.1 s transition); 3115 drone external winding machine specification (4 stations recommended).
How does the stator core constrain fully automatic winding machine performance?
The stator core sets the physical boundary conditions the winding machine must work within. Slot opening geometry determines whether an automated needle or flyer can enter and how much effective slot area is available. Insulation coating integrity determines how much tension the enamel can survive before a turn-to-turn short occurs. Burr height on lamination edges can pierce the coating during winding and create a latent short. Dimensional tolerance controls how consistently the stator seats in the winding fixture. Reenives publishes drone stator cores with 0.20 mm silicon steel, core loss ≤8.5 W/kg at 1.0 T / 400 Hz, stacking factor ≥97.5%, burr height <0.03 mm, and epoxy coating. A winding machine cannot compensate for a stator core that is out of tolerance or has a compromised coating.
Source: Reenives drone stator stamping lamination specification (0.20 mm, ≤8.5 W/kg, ≥97.5% stacking factor, <0.03 mm burr, epoxy coating).
Summary: Automate the Process, Not Just the Motion
Fully automatic stator winding machines for drone motors are not qualified by their automation label or their station count. They are qualified by the process parameters they can hold repeatably: tension fluctuation within ±3% and as tight as ±0.05 N for high-end equipment; wire placement accuracy within ±0.02 mm; slot fill capability that reaches 75–80% where the stator core’s slot opening allows, versus the 30–40% of manual winding; and multi-station architecture that overlaps winding and handling to double capacity. A machine that automates the motion but misses the parameters is a fast machine with a latent defect rate.
The stator core is the physical input that sets the ceiling. Reenives publishes drone stator cores with 0.20 mm silicon steel, core loss ≤8.5 W/kg at 1.0 T / 400 Hz, stacking factor ≥97.5%, and burr height <0.03 mm. Those specifications determine whether the winding machine can enter the slot, survive the tension, and seat the stator consistently. A winding machine and a stator core are a matched pair, and neither can be selected in isolation.
The step that separates a successful purchase from a costly retrofit is the trial wind. Send sample stators and the production wire to the machine supplier, have them run the wind, and inspect wire lay, slot fill, and any signs of damage before discussing price. Then confirm the hidden-cost checklist — fixtures, auto-loading, MES integration, freight, installation, and commissioning — and calculate the total cost against the production plan. The machine that passes the trial wind is the machine that will pass the 1,000th stator.
Specifying stator cores for a fully automatic winding programme?
Reenives manufactures precision stamped stator laminations for drone BLDC motors: 0.20 mm silicon steel, core loss ≤8.5 W/kg at 1.0 T / 400 Hz, stacking factor ≥97.5%, burr height <0.03 mm, and epoxy coating, in slot/pole configurations including 9N12P, 12N14P, 18N24P, and 24N28P. Private mould development and free samples are available for qualified drone and BLDC motor programmes.
WhatsApp: +86-13377741885
Email: linda_reenives@163.com
Official website: www.reenives-bldcmotor.com
Dongguan Runlu Motor Technology Co., Ltd.
Reenives — Drone Motor One-Stop Solution Supplier
Reenives is a professional drone stator core manufacturer, founded in 2022. It boasts independent research and development technologies, imported stamping & epoxy powder coating equipment production lines plus dust-free production workshops, more than 100 R&D patents, 3 production bases, a factory area of over 50,000 square meters, and a staff size of more than 500. From production to sales, we support bulk purchasing, private mould development, and sample making, and can provide tailor-made perfect solutions for your production and usage scenarios. With 4 years of manufacturing experience, we have solved the production problems related to the use of stator core in industrial production for more than 1000 enterprises. We can ship globally (with complete export qualifications). Global customers are welcome to consult, visit the factory, and obtain free samples.
0.20 mm silicon steelCore loss ≤8.5 W/kg @ 1.0 T / 400 HzStacking factor ≥97.5%Burr <0.03 mmEpoxy coating9N12P · 12N14P · 18N24P · 24N28PGlobal export qualifications
Drone Motor Winding Stator Parameters Explanation
How to Fulfull Drone Motor Stator Winding?
Related Article