How to Choose BLDC Drone Electric Motor Winding Machine?

How to Choose a BLDC Drone Electric Motor Winding Machine: Tension, Slot Fill, and the Stator It Must Match
Most drone winding machine purchasing mistakes are not machine failures — they are matching failures. A buyer specifies a flyer winder with a high RPM spindle, installs it, and discovers that the stator’s slot orientation requires a needle machine. Or the machine holds tension at ±20 g when the 0.18 mm wire needs ±5 g, and the enamel is micro-damaged on the first production batch. Or the slot fill lands at 35% because the winding pattern was never optimized for the stator’s tooth geometry, and the motor that was designed for 70% fill underperforms on the thrust stand. The machine was delivered as specified. The specification was wrong.
The published parameters show how narrow the matching window is. Drone stator wire runs from AWG 28 to AWG 34, approximately 0.1 mm to 0.25 mm. A drone-specific flyer machine holds tension at ±5 g to prevent breakage and over-stretching. Traditional manual or low-tier winding yields a slot fill factor of roughly 30% to 40%; advanced machines with multi-axis CNC positioning and layered winding patterns push copper density substantially higher within the same slot. And the stator itself — its slot orientation, insulation coating, burr height, and dimensional tolerance — sets the physical boundary conditions the machine must work within.
This guide is written for the process engineer or procurement lead who has to specify, quote, and commission a BLDC drone motor winding machine. It separates the machine architectures by stator geometry, presents the published tension, wire, accuracy, and cost parameters with their sources, maps the machine choice to drone mission profiles, and closes with a five-step selection workflow that includes the stator core audit the machine alone cannot perform. Every figure below is traceable to a published equipment specification or a named industry source.
In this guide — jump to the section your project needs:
- What Is a BLDC Drone Winding Machine? The Matching Problem Defined
- Winding Machine Architectures: Flyer, Needle, and Semi-Automatic vs Fully Automatic Lines
- Published Parameters: Tension, Wire Diameter, Slot Fill, Speed, Accuracy, and Cost Bands
- Application Profiles: Which Machine Configuration Binds Which Drone Mission
- A 5-Step Selection Workflow Including the Stator Core Audit
- FAQ: Flyer vs Needle, Tension, Slot Fill, Dimensions, Cost, and Stator Compatibility
- Summary: Match the Machine to the Stator, Not the Spec Sheet
What Is a BLDC Drone Winding Machine? The Matching Problem Defined
A BLDC drone motor winding machine is a specialized piece of production equipment that places enameled copper wire into the stator slots of a brushless drone motor in a defined pattern, with a defined number of turns, under controlled tension. It is not a general-purpose coil winder scaled down. Drone stators are small — typically 15 mm to 40 mm in diameter, with 9 or 12 slots — and the wire is extremely thin, AWG 28 to AWG 34, roughly 0.1 mm to 0.25 mm, chosen to pack as many turns as possible into the slot and generate the required electromagnetic flux. The machine must place hundreds of turns of fragile wire into a confined space without a single break, scuff, or slack turn, and the margin for error is vanishingly small.
The matching problem has four dimensions, and a machine that fails on any one of them will not produce a reliable drone stator regardless of its RPM rating or automation level.
| Matching Dimension | What It Determines | Published Drone Reference | Failure If Mismatched |
|---|---|---|---|
| Slot orientation | Whether a flyer or needle architecture is physically capable of reaching the slot | Outward-facing slots on 12N14P outrunners → flyer winding; inward-facing slots → needle winding | Machine cannot wind the stator at all, or winds it with damaged wire |
| Wire diameter and tension window | Whether the enamel survives the winding process | 0.18–0.25 mm single strand or 3×0.12–4×0.13 mm parallel; ±5g precision tension control | Turn-to-turn short, wire breakage, resistance imbalance |
| Slot fill factor capability | Copper density, and therefore Kt and resistance | Manual/low-tier: 30–40%; advanced multi-axis CNC with layered patterns: substantially higher | Motor underperforms its torque constant and overheats at the designed current |
| Stator core quality | The physical boundary the machine must work within | Coating uniform and pinhole-free; critical tolerance ±0.05 mm; burr height controlled | Burrs pierce coating during winding; eccentric bore prevents consistent seating |
Sources: Published drone motor winding analysis (stator 15–40 mm, AWG 28–34, flyer winding for outrunners); 3115 drone winding machine specification (0.18–0.25 mm wire, ±5g tension); Qiwei drone winding selection guide (manual 30–40% slot fill, CNC layered patterns); Reenives stator core specification (coating, tolerance).
Procurement translation: a winding machine quotation that lists RPM, station count, and price has not addressed the matching problem. The specification must name the stator slot orientation, the wire diameter range, the tension window, the slot fill target, and the stator core’s coating and tolerance. A machine that meets all five is a matched machine; a machine that meets three is a machine that will require process development, rework, or a stator redesign after installation.
Winding Machine Architectures: Flyer, Needle, and Semi-Automatic vs Fully Automatic Lines
Flyer versus needle: the architecture decision
| Architecture | Winding Mechanism | Best Suited For | Drone Relevance |
|---|---|---|---|
| Flyer winding (outer slot) | High-speed rotating fork orbits the stator; wire is guided into outward-facing slots | Outrunner drone motors, heavy-lift agricultural drones, RC aircraft; stators accessible from outside | Mainstream production method for 12N14P drone outrunners |
| Needle winding (inner slot) | Precision nozzle moves in and out through narrow slot openings facing inward | Pumps, power tools, internal-slot stators, some micro-drone and targeted internal profiles | Not the default for drone outrunners; needle winding is impractical for many outrunner stators because the stator is accessible from the outside |
Sources: Published flyer versus needle selection guidance (slot orientation determines architecture; flyer for outward-facing slots common in drones and RC); drone-specific winding analysis noting needle winding impractical for many outrunner stators.
The architecture decision is not a preference. A flyer machine cannot wind a stator whose slots face inward, because the flyer orbits outside the stator and the wire has no path to the slot. A needle machine can theoretically reach some outward-facing configurations, but it is slower and more costly, and for drone outrunners the flyer is the mainstream production method. The practical selection rule from published winding guidance is unambiguous: slots facing inward require a needle inner-winding machine; slots facing outward suit a flyer outer-winding machine.
Semi-automatic versus fully automatic
Within the flyer architecture, the automation level determines throughput, changeover flexibility, and where the operator remains in the process.
| Configuration | Automation Level | Published Capability | Best Fit |
|---|---|---|---|
| Semi-automatic flyer | Automatic winding and indexing; manual loading, wire routing, and unloading | Single or dual station; servo + PLC + touchscreen; recipe storage; 800–1500 rpm | Prototyping, low-volume, and multi-model production |
| Fully automatic flyer line | Automatic feeding, winding, indexing, wire arrangement, cutting, and unloading | 4-station recommended for mass production; MES integration; ±0.01 mm assembly positioning on integrated lines | High-volume FPV and UAV motor production with a stable model mix |
| Integrated stator winding module in a motor line | Winding embedded in a multi-process drone motor assembly line | Covers stator winding, rotor magnet press-fitting, stator-rotor assembly, and performance testing; MES traceability; 29 main processes with zero manual intervention on some lines | Buyers commissioning a full drone motor production line rather than a stand-alone winder |
Sources: 3115 drone winding machine specification (servo + PLC + touchscreen, recipe storage, automatic functions); Jiuju drone motor assembly line (stator winding integrated, MES traceability, 29 processes); published flyer machine station configurations (dual vs quad).
The automation decision is a volume decision, not a quality decision. A semi-automatic flyer with a precision tension controller can produce a stator as electrically clean as a fully automatic line; it simply does so at a lower throughput and with more operator dependency at the loading and unloading stations. The fully automatic line’s value appears when the annual volume justifies the tooling and integration cost, and when the model mix is stable enough that changeover time does not erode the throughput advantage. Published drone motor line data describes changeover times of around 25 minutes for multi-specification micro-motor production, which sets the practical floor for a flexible high-volume configuration.
Published Parameters: Tension, Wire Diameter, Slot Fill, Speed, Accuracy, and Cost Bands
Tension: the parameter that decides whether the enamel survives
Tension control is the heart of drone motor winding, because the wire is thin enough that a momentary tension surge can cause micro-damage to the enamel coating that may not be detected until the motor fails after hours of flight. Published drone-specific equipment uses a precision tension controller at ±5 g to prevent breakage of fine wires and over-stretching. Closed-loop electronic tensioners with a dancer arm and load cell keep wire stress constant, typically below 20 grams-force. Broader winding-system data places closed-loop tension fluctuation within ±0.05 N and wire placement accuracy better than ±0.03 mm. The two failure modes are symmetric: excessive tension stretches and thins the enamel, creating a turn-to-turn short risk; insufficient tension leaves a loose coil that vibrates under flight loads and can short against adjacent turns.
Wire diameter, turns, and the KV relationship
Published drone-specific winding data gives the wire and turn parameters directly. The 3115 drone motor external winding machine handles 0.18–0.25 mm single-strand wire or 3×0.12–4×0.13 mm parallel winding, and for a KV900 rating uses approximately 12 turns per phase, which is 4 turns per slot across 3 slots per phase. The broader drone stator range is AWG 28–34, or roughly 0.1–0.25 mm. The turns count sets KV, and the wire diameter sets current capacity; the machine must handle both within its tension window, because a machine optimized for 0.18 mm wire may not hold tension accurately on a 0.25 mm strand, and a machine set for a coarse wire may over-tension a fine one.
Slot fill factor: the copper-density metric
Slot fill factor is the ratio of copper cross-sectional area to total available slot space. Published selection guidance puts traditional manual or low-tier machine winding at roughly 30% to 40% slot fill because of unorganized wire crossovers and air gaps. Advanced drone winding machines use multi-axis CNC positioning to execute layered or interleaved winding patterns, maximizing copper density within the same slot. The motor-level consequence is direct: higher fill factor increases the torque constant (Kt) and reduces line-to-line resistance (R) without altering the motor’s physical footprint. The stator core’s slot opening geometry and coating integrity set the ceiling on what any machine can achieve.
Speed, accuracy, and station count
Published drone-specific flyer machines run at 800–1500 rpm, with dual-station and quad-station configurations; four stations are recommended for mass production. General flyer machines can reach higher spindle speeds, but for thin drone wire the practical constraint is tension control and wire break detection, not raw RPM. Integrated motor assembly lines publish ±0.01 mm assembly positioning accuracy, but that figure describes the assembly line’s positioning capability, not the winding machine’s wire placement. The winding-specific accuracy figure to request is the wire placement accuracy, published at better than ±0.03 mm on high-performance systems.
Cost bands and the drivers behind them
Published price ranges for drone brushless stator winding machines fall between roughly 90,000 and 150,000 RMB for production-grade equipment. The broader market shows external flyer machines starting around 60,000–80,000 RMB, internal needle machines generally above 100,000 RMB, and drone-specific high-precision internal winders quoted in the 50,000–120,000 RMB range. The price drivers are specific: multi-station machines cost 20–40% more than single-axis; imported servo, guide rail, and screw components add 20–30% over domestic equivalents; non-standard customization adds 20–50% and extends lead time from roughly 20–30 days to 30–60 days. Fixtures, auto-loading mechanisms, MES integration, and special wire tension debugging are often quoted separately and should be confirmed before signing.
The hidden-cost checklist: published purchasing guidance for automatic stator winders flags the items most often assumed to be included but quoted separately — fixtures and molds, automatic loading/unloading mechanisms, MES data integration, tension parameter debugging for special wire (ultra-fine or self-bonding), freight, taxes, and installation/commissioning. A machine quotation that omits these lines is not comparable to one that includes them, and the gap can exceed the price difference between two machine models.
Application Profiles: Which Machine Configuration Binds Which Drone Mission
| Mission Class | Stator / Wire Profile | Binding Machine Configuration | Why |
|---|---|---|---|
| FPV racing / high-RPM | Small 12N14P outrunner; 0.18–0.25 mm wire; high turns count | Flyer, dual-station, ±5g tension, wire break detection | Fine wire at high speed is prone to breakage; a single break can wrap the stator and damage previously wound coils before the machine stops |
| Cinematic / inspection | 12N14P; moderate wire; emphasis on turn-count consistency | Flyer with programmable winding patterns and end-winding height control | Motor-to-motor resistance variation causes uneven thrust and vibration that reaches the camera; consistent coil geometry matters more than maximum RPM |
| Agricultural / heavy-lift | Larger outrunner; thicker wire or parallel strands; high current | Flyer, quad-station, multi-strand tension control | Higher current demands more copper; parallel strands mitigate skin effect and require uniform tension across strands |
| Micro / whoop-class | Very small stator; 0.1 mm-class wire | Flyer with precision tension at the fine-wire limit; possibly needle for internal-slot variants | The tension window is narrowest at the smallest wire diameter; a standard tensioner may not resolve the required force accurately |
| Full motor production line | Multiple stator SKUs; volume production | Integrated winding module within a motor assembly line; MES traceability; automatic loading | The winder becomes one station in a chain that includes magnet insertion, balancing, and end-of-line testing; the integration capability matters as much as the winder’s standalone performance |
The pattern is that the binding machine configuration tracks the wire diameter and the current demand. FPV and micro platforms bind on tension resolution and wire break detection, because the wire is thinnest and the consequences of a single break are most severe. Cinematic platforms bind on turn-count consistency and end-winding geometry, because vibration and thrust imbalance are the visible failure. Agricultural and heavy-lift platforms bind on multi-strand capability and station count, because copper volume and throughput are the constraints. A full production line binds on integration and traceability, because the winder’s output must be matched to the rotor and test stations downstream.
A 5-Step Selection Workflow Including the Stator Core Audit
- Determine the stator slot orientation before comparing machine architectures. Confirm whether the slots face outward (outrunner drone motor) or inward (internal-slot motor). Outward-facing slots point to a flyer winding machine; inward-facing slots require a needle machine. This is the first decision, and it eliminates roughly half the market before price comparison begins. Published drone outrunner guidance is consistent: flyer winding is the mainstream method for 12N14P outrunners, and needle winding is impractical for many outrunner stators because the stator is accessible from the outside.
- Define the wire diameter range and the tension window, then require the machine to hold it. State the wire diameters and strand configurations the production plan requires — for example 0.18–0.25 mm single strand and 3×0.12–4×0.13 mm parallel for a 12N14P drone stator. Require a precision tension controller at ±5g, or a closed-loop system within ±0.05 N, and ask for the tension fluctuation test report. A machine that quotes a tension range but not a resolution has not specified the parameter that prevents enamel damage.
- Set a slot fill target and ask how the machine achieves it. Published manual and low-tier winding lands at 30–40% fill. If the motor design assumes a higher fill, the machine must have multi-axis CNC positioning and programmable layered or interleaved winding patterns. Ask for the fill factor achieved on a sample stator with the production wire, not a theoretical maximum. The stator core’s slot opening geometry and coating integrity set the ceiling on what the machine can achieve, so this step connects directly to the next.
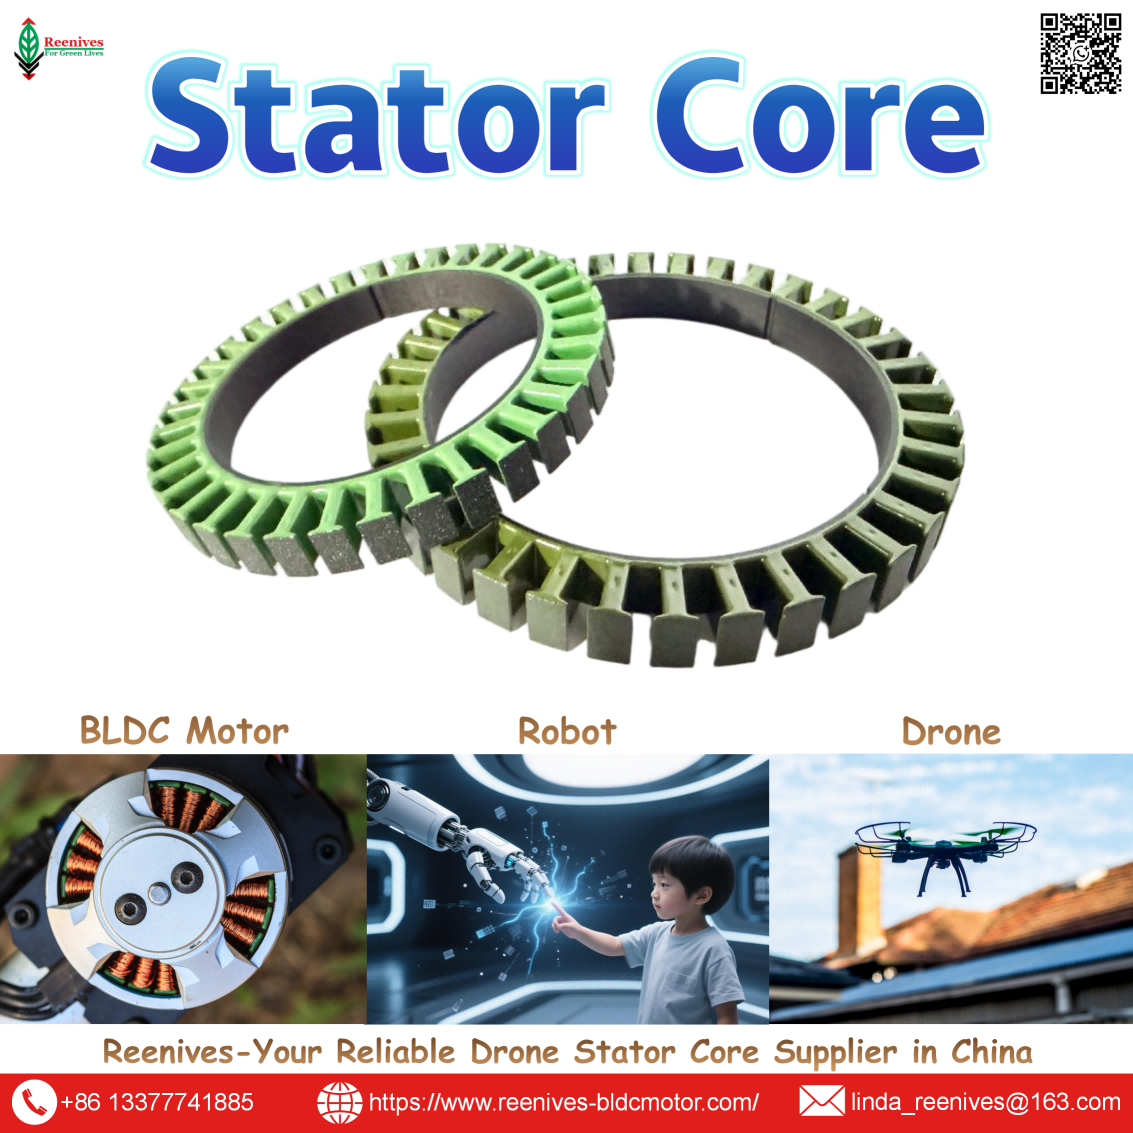
- Audit the stator core that the machine will wind. The machine cannot compensate for a stator with a compromised coating, excessive burr, or an out-of-tolerance bore. Require the stator core to be specified with a uniform, pinhole-free epoxy powder coating, controlled burr height, and critical-dimension tolerance at or better than ±0.05 mm. Reenives publishes stator cores with epoxy powder coating, ±0.05 mm critical tolerance, and slot/pole configurations including 6S/4P, 9S/6P, 12S/14P, and 24S/28P. A stator with burrs that pierce the coating during winding creates a latent short that no machine setting can detect.
- Send sample stators and wire for a trial wind before committing to the purchase. Published purchasing guidance is explicit: send 2–3 stator samples and the wire specification to the machine supplier and have them run a trial wind, then inspect wire lay, slot fill, and any signs of wire damage or skipping. Only after the sample passes should price and configuration be discussed. A winding machine is not a plug-and-play purchase; process matching matters more than a few thousand in price difference. Then confirm the hidden-cost checklist — fixtures, auto-loading, MES integration, freight, installation, and commissioning — and calculate the total cost against the production plan.
FAQ: Flyer vs Needle, Tension, Slot Fill, Dimensions, Cost, and Stator Compatibility
What is the difference between a flyer winding machine and a needle winding machine for drone stators?
The choice is dictated by stator slot orientation. A flyer winding machine uses a high-speed rotating fork that guides the wire into slots facing outward — the standard configuration for outrunner drone motors, where the stator is accessible from the outside. A needle winding machine uses a precision nozzle that moves in and out through narrow slot openings facing inward, which is suited to internal-slot stators such as pumps and power tools. For 12N14P drone outrunners, flyer winding is the mainstream production method; needle winding is impractical for many outrunner stators because the stator is accessible from the outside. Published drone-specific flyer machines handle 0.18–0.25 mm single-strand wire and run at 800–1500 rpm with ±5g tension control.
Source: Published flyer vs needle selection guidance (slot orientation); drone-specific winding analysis (flyer mainstream for outrunners, needle impractical); 3115 drone winding machine specification (wire range, speed, tension).
What tension tolerance should a drone stator winding machine hold?
For drone-grade fine wire, the tension window is narrow. Published drone-specific winding equipment uses a precision tension controller at ±5g to prevent breakage of fine wires and over-stretching. Other published winding-system data places closed-loop tension fluctuation within ±0.05 N and wire placement accuracy better than ±0.03 mm. A closed-loop electronic tensioner with a dancer arm and load cell keeps wire stress constant, typically below 20 grams-force. Excessive tension stretches and thins the enamel coating, creating a turn-to-turn short risk that may not appear until the motor fails after hours of flight; insufficient tension leaves loose coils that vibrate and can short under flight loads.
Source: 3115 drone winding machine specification (±5g precision tension controller); published closed-loop tension data (±0.05 N fluctuation, below 20 gf wire stress, ±0.03 mm placement accuracy).
What slot fill factor can a drone winding machine achieve, and why does it matter?
Slot fill factor is the ratio of copper cross-sectional area to the total available slot space. Published data puts traditional manual or low-tier machine winding at roughly 30% to 40% slot fill because of unorganized wire crossovers and air gaps. Advanced drone winding machines use multi-axis CNC positioning to execute layered or interleaved winding patterns, maximizing copper density within the same slot. Higher fill factor directly increases the torque constant (Kt) and reduces line-to-line resistance (R) without changing the motor’s physical footprint. The stator core’s slot opening geometry and insulation coating integrity set the ceiling on what the winder can achieve.
Source: Qiwei drone winding machine selection guide (manual 30–40% slot fill; CNC layered patterns for higher density).
What stator dimensions and wire diameters should a drone winding machine cover?
A drone motor stator is typically small, often 15–40 mm in diameter with 9 or 12 slots. Wire diameters run from AWG 28 to AWG 34, approximately 0.1 mm to 0.25 mm. Published 3115 drone motor winding machine specifications cover 12 slots, 31 mm outer diameter, 15 mm stack thickness, and 13 mm inner diameter, with 0.18–0.25 mm single-strand or 3×0.12–4×0.13 mm parallel winding. Standard BLDC needle winding machines cover a broader range — wire Φ0.13–1.2 mm and stator OD Φ60–200 mm — but a drone-specific machine is optimized for the small-stator, fine-wire regime rather than the general industrial range.
Source: Published drone stator winding analysis (15–40 mm diameter, 9–12 slots, AWG 28–34); 3115 drone winding machine specification (31 mm OD, 15 mm stack, 0.18–0.25 mm wire); standard BLDC needle machine specification (Φ0.13–1.2 mm wire, Φ60–200 mm OD).
How much does a BLDC drone stator winding machine cost, and what drives the price?
Published price ranges for drone brushless stator winding machines fall between roughly 90,000 and 150,000 RMB for production-grade equipment. More broadly, external flyer machines start around 60,000–80,000 RMB, while internal needle machines generally exceed 100,000 RMB, with drone-specific high-precision internal winders quoted in the 50,000–120,000 RMB range. Price is driven by winding method (needle versus flyer), station count (multi-station machines cost 20–40% more than single-axis), core component origin (imported servo, guide rail, and screw components add 20–30% over domestic equivalents), and customization level (standard models ship in about 20–30 days; non-standard designs add 20–50% and 30–60 days). Fixtures, auto-loading mechanisms, and MES integration are often quoted separately.
Source: Vacuz drone winding machine price data (90,000–150,000 RMB); Nuoyuan price analysis (flyer vs needle cost, station premium, component origin, customization premium, hidden costs).
How does the stator core affect winding machine performance and selection?
The stator core sets the physical boundary conditions the winding machine must work within. Slot opening geometry determines whether a flyer or needle approach is feasible. Insulation coating integrity determines how much tension the enamel can survive before a turn-to-turn short occurs. Burr height on the lamination edges can pierce the coating during winding and create a latent short. Dimensional tolerance controls how consistently the stator seats in the winding fixture. Reenives publishes stator cores with epoxy powder coating that is uniform and pinhole-free, critical-dimension tolerance of ±0.05 mm, and slot/pole configurations including 6S/4P, 9S/6P, 12S/14P, and 24S/28P. A winding machine cannot compensate for a stator core that is out of tolerance or has a compromised coating.
Source: Reenives stator core specification (epoxy powder coating, ±0.05 mm critical tolerance, 6S/4P, 9S/6P, 12S/14P, 24S/28P slot/pole configurations).
Summary: Match the Machine to the Stator, Not the Spec Sheet
Choosing a BLDC drone electric motor winding machine is not a search for the highest RPM or the lowest price. It is a matching problem with four dimensions: slot orientation decides flyer versus needle; wire diameter and tension window decide whether the enamel survives; slot fill capability decides whether the motor reaches its designed Kt and resistance; and stator core quality sets the physical boundary the machine must work within. A machine that matches on all four is a production asset. A machine that matches on three is a process-development project waiting to happen.
The published parameters are concrete. Drone-specific flyer machines run 800–1500 rpm with ±5g tension on 0.18–0.25 mm wire, producing approximately 12 turns per phase for a KV900 rating. Manual and low-tier winding lands at 30–40% slot fill, while advanced multi-axis CNC with layered patterns pushes copper density higher within the same slot. Production-grade drone winding machines fall in the 90,000–150,000 RMB range, with needle architectures, multi-station configurations, imported components, and non-standard customization each adding their own premium. Fixtures, auto-loading, MES integration, and installation are frequently quoted separately.
The step that separates a successful purchase from a costly retrofit is the trial wind. Published purchasing guidance is unambiguous: send sample stators and the production wire to the supplier, have them run the wind, and inspect the wire lay, slot fill, and any signs of damage before discussing price. And because the stator core is the machine’s physical input, the stator specification — uniform pinhole-free coating, controlled burr, ±0.05 mm critical tolerance, and a defined slot/pole configuration — belongs in the same conversation as the winding machine quotation. The machine and the stator are a matched pair, and neither can be selected in isolation.
Specifying stator cores for a drone winding programme?
Reenives manufactures precision laminated stator and rotor cores engineered for drone winding processes: uniform, pinhole-free epoxy powder coating for enamel protection, critical-dimension tolerance ±0.05 mm, slot/pole configurations including 6S/4P, 9S/6P, 12S/14P, and 24S/28P, and matched stator-rotor pairs. Private mould development and free samples are available for qualified drone and BLDC motor programmes.
WhatsApp: +86-13377741885
Email: linda_reenives@163.com
Official website: www.reenives-bldcmotor.com
Dongguan Runlu Motor Technology Co., Ltd.
Reenives — Drone Motor One-Stop Solution Supplier
Reenives is a professional drone stator core manufacturer, founded in 2022. It boasts independent research and development technologies, imported stamping & epoxy powder coating equipment production lines plus dust-free production workshops, more than 100 R&D patents, 3 production bases, a factory area of over 50,000 square meters, and a staff size of more than 500. From production to sales, we support bulk purchasing, private mould development, and sample making, and can provide tailor-made perfect solutions for your production and usage scenarios. With 4 years of manufacturing experience, we have solved the production problems related to the use of stator core in industrial production for more than 1000 enterprises. We can ship globally (with complete export qualifications). Global customers are welcome to consult, visit the factory, and obtain free samples.
Uniform pinhole-free epoxy coatingCritical tolerance ±0.05 mm6S/4P · 9S/6P · 12S/14P · 24S/28PMatched stator + rotor pairsPrivate mould developmentGlobal export qualifications
How to Fulfull Drone Motor Stator Winding?
Reenives: Global Leading Drone Motor Parts Supplier
Related Article